TJ, Jim, Arnaud
Implemented a new HAM3_CRS guardian. The purpose of this guardian is to :
1) monitor the state of the CRS on HAM3 (Laser status, 25mHz tilt amplitude, and readout noise (3_10Hz)
2) adjust the damping gain depending on the tilt amplitude, and
3) take it to "SAFE" (Damping OFF) when maintenance is necessary
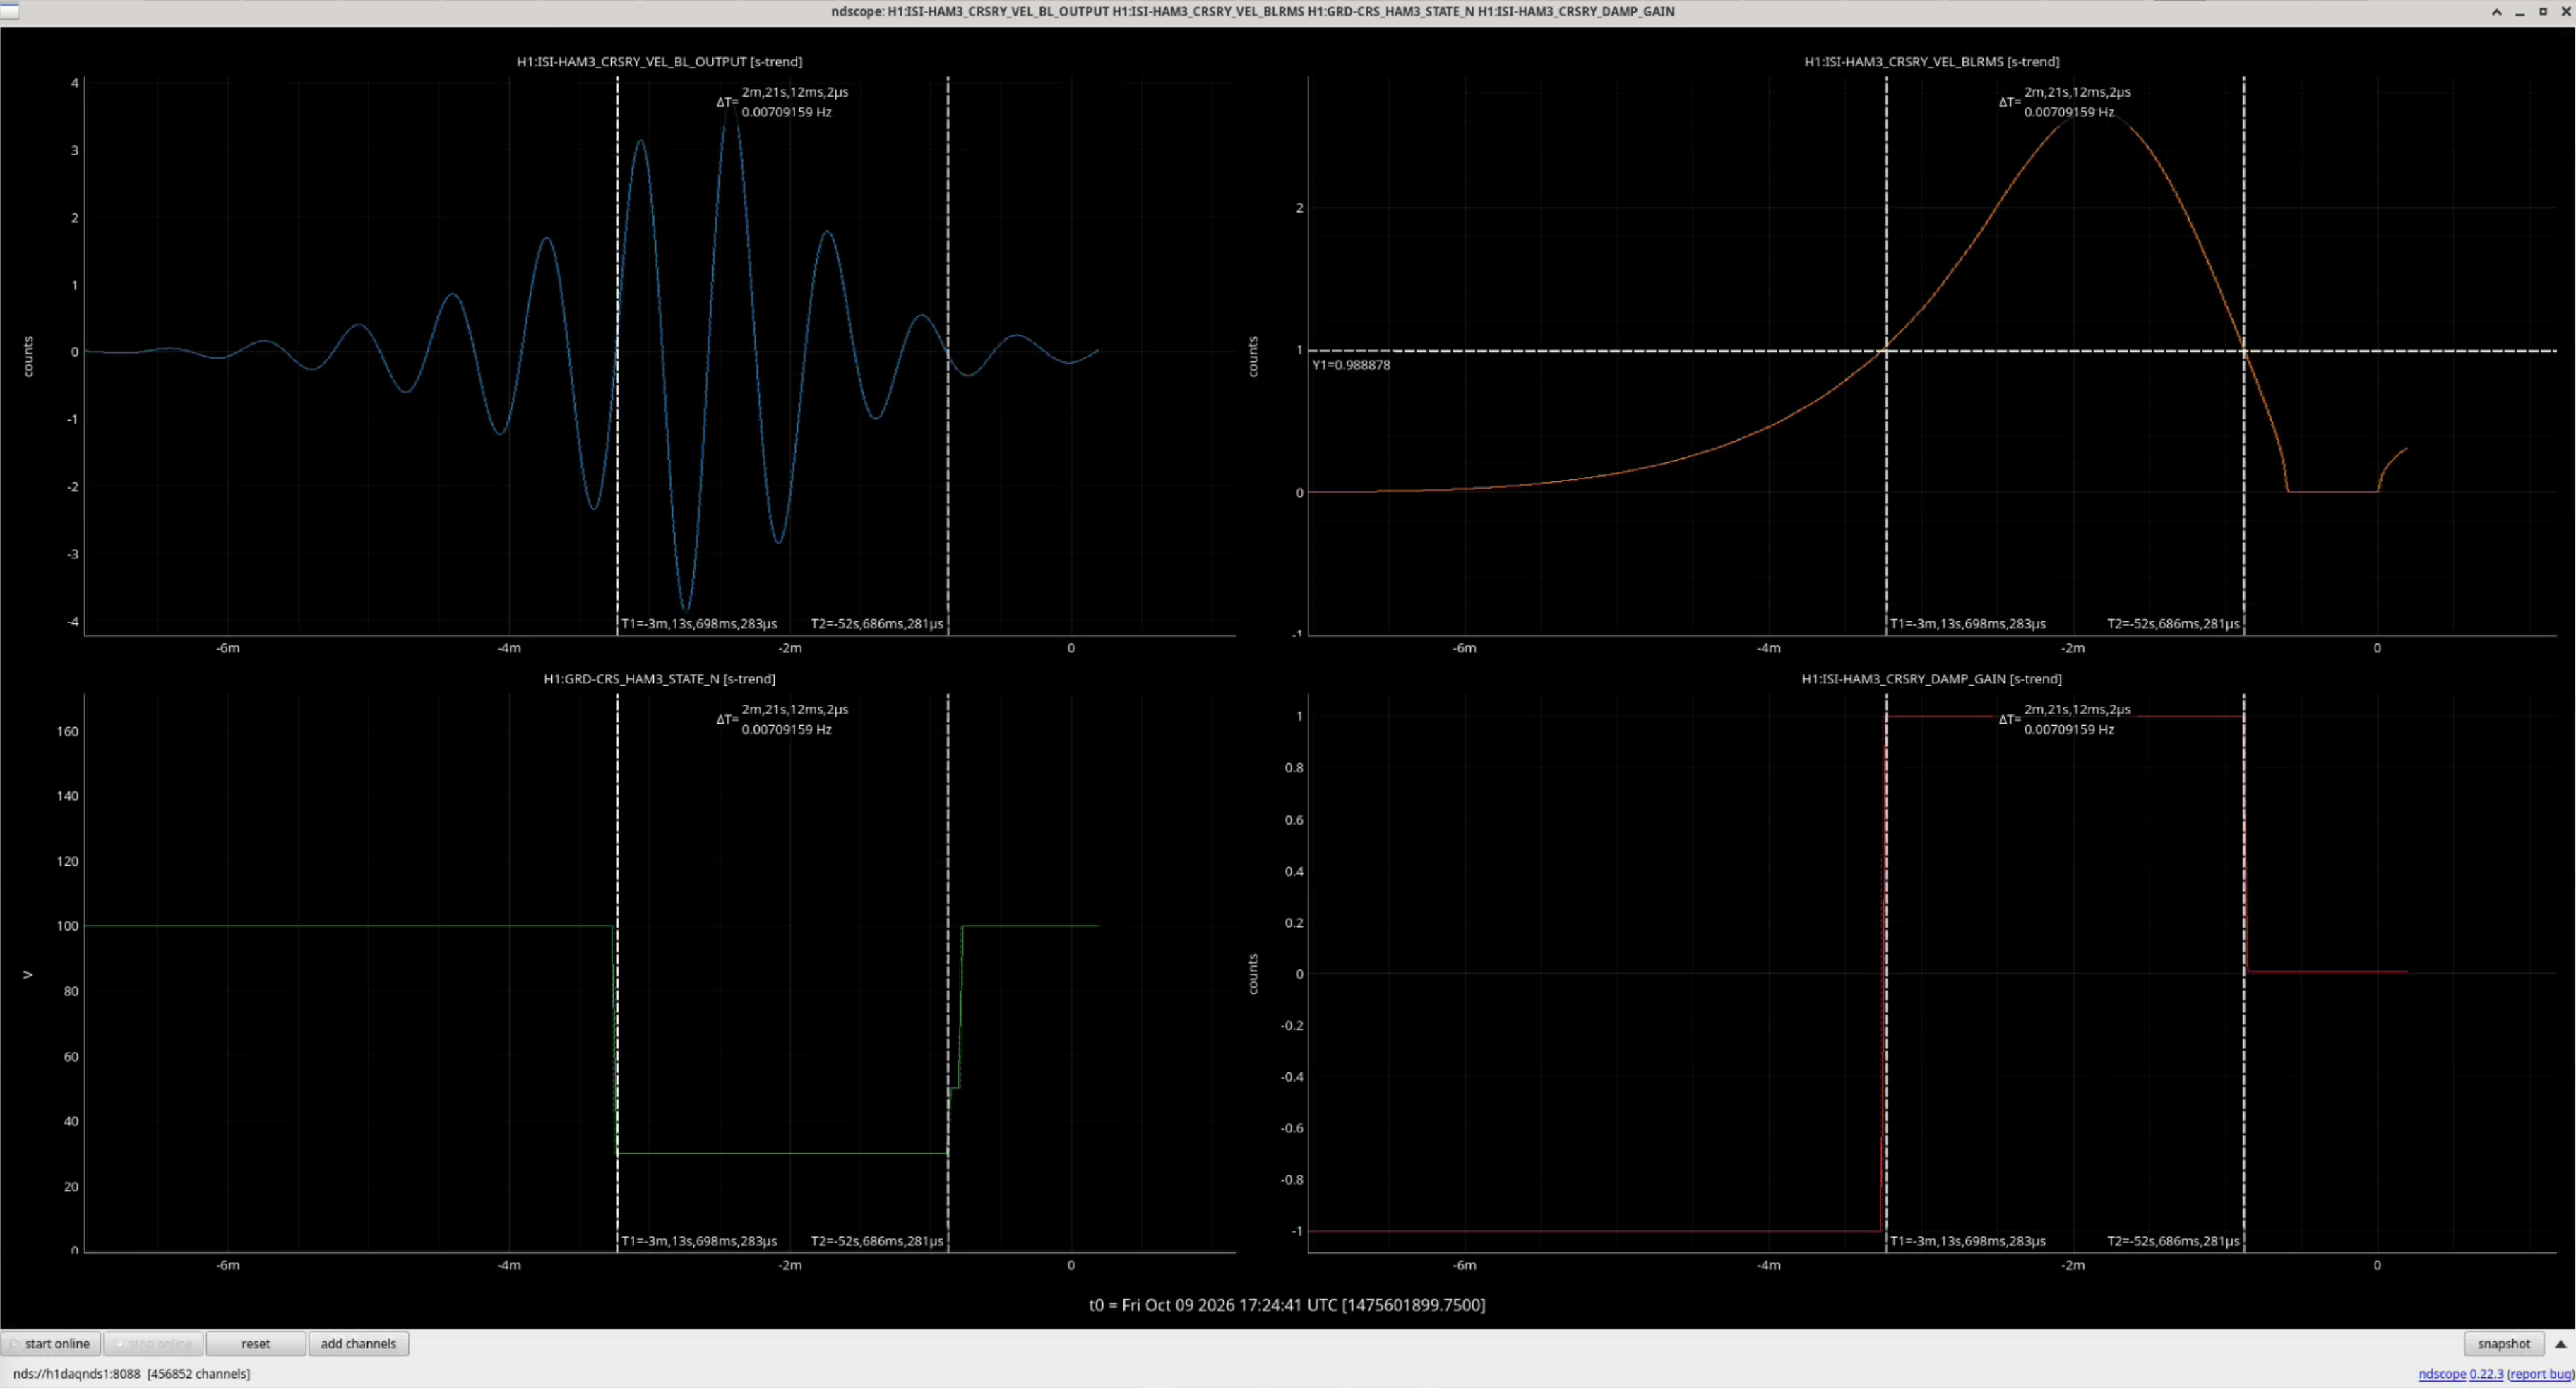
This morning, we tested the condition for a rung up CRS, see attached screenshot. The CRS was manually rung up, and we let the guardian take over. After the 1urad rms threshold was reached, guardian jumped to CRS_RUNG_UP state, changed the damping gain to 1 (from nominal 0.01), and went back to CRS_GOOD after the RMS threshold came back under threshold. The earthquake that happened later today also triggered the CRS_RUNG_UP state as expected, see second plot from this alog
Guardian logic description is written under: T2600479