[Louis, Elenna, with input from Sheila, Daniel, others]
Elenna and I measured the PRC Gouy phase using the inertial kick technique used by Stefan et al in the past. Some relevant links to past PRC inertial kick measurements are 52504, 66215. Elenna's alog from a few days ago describing the SRC gouy results is also very relevant: 92136.
We measure the single pass Gouy phase in the PRC to be 17.78° +/- 0.02°.
This differs from the most recent measurements in 2022 (66215, 20.66° +/- 0.17°) by about 2.88° and from the 2019 measurements (52504, 23.23° +/- 0.17°) by about 4.45°.
Ring heaters were set to 0W during this test (92075).
We followed the 'Measurement2' procedure from 52504. It took a few tries to get it right. We used H1:LSC-PRCL2_OUT as a trigger channel. We used an offset of -1e6 and used the engagement of said offset as the data start time. We got 5 kick measurements, ranging from 5 - 13 FSRs (page 1 of prc_gouy_sept_2026.pdf).
The diaggui templates we used live as ~elenna.capote/inertial_gouy/PRC_gouy_kick<1-5>.xml. Those templates have a lot of channels. The primary channel used in my analysis is H1:LSC-POPAIR_B_LF_OUT. Unfortunately I did not get the corresponding IOP fast channel for that channel. It's not necessary but would have been nice to have to get more samples across each of the resonances. I did record the fast channel POPX segment data for future followup.
I have a few thoughts on how we can get a better measurement next time there's an opportunity to repeat this. I'll state some brief comments here to remind future me to expand on this more clearly: 1.) it would be great to *not* feed REFL to PRCL during the measurement, 2.) we should revisit trying to hold MICH on a dark fringe instead of continuing to let it actuate during the swing, 3.) we should use the trigger method we used for SRC to get a more deterministic measurement, 4.) do we really need full PRMI to get this measurement?
I exported the trigger (LSC-PRCL2_OUT) and readback (LSC-POPAIR_B_LF_OUT) channel data to txt files stored at ~elenna.capote/inertial_gouy/prc_data/. There is a short description of what each txt file is in notes.txt. The processing script is at analyze.py in the same directory. It is also on gitlab.
Before I started writing alog entry, I was quite concerned with the result of ~18° mostly because it seems like such a large deviation from the ~23° measurement from 2019. I didn't appreciate that the more recent 2022 measurement is much closer at 20.66°. As a sanity check for myself, I used my analysis script to process a subset of one of the preceding gouy measurements to make sure that I get a similar answer. I processed one of the 2019 measurements from 52504 and uploaded the resultant plot to prc_gouy_52504_sanity_check.pdf. My result is within 0.1° of what's reported in that entry.
I don't yet have a good explanation for why the gouy phase has changed this much. The most 'obvious' thing to point at is the new bigger beam splitter. Sophie and I are planning to run some tests with Finesse this week to figure out what amount of lensing (presumably at the BBS) would account for the delta in gouy phase we're seeing in the PRC and SRC.
In the attached prc_gouy_sept_2026.pdf I have several diagnostic plots:
- Page 1: time series of each of the 5 measurements. vertical counts is from POPAIR_B_LF_OUT.
- Pages 2-6: overlays in time and fractional FSR spacing for each measurement set. both subplots are aligned so the 00 peaks lay at the horizontal origin. The temporal overlays indicate that the PRM was accelerating throughout the measurement. The changing velocity had to be accounted for. The FSR overlay shows the 01+10, 02+20 modes line up pretty well after using a cubic spline on the velocity. I believe the bump at 0.5 FSR could be the sidebands.
- Page 7: the speed of the PRM through each measurement set (kick). The speed is evaluated at the mid point between each set of successive 00 peaks.
- Page 8: displacement of the PRM across each measurement set (kick) as a function of time elapsed since the first 00 peak.
- Page 9: measured single pass gouy phases for each measurement set. The black horizontal line is the mean of the means and the gray shaded region spans mean +/- std mean error. The kick2 and kick3 measurements both contain outliers that deviate from the rest by more than their errorbars. This kind of thing can likely be tightened up by 1.) carefully retaking the measurement in a more deterministic configuration and/or 2.) being more careful of how I'm handing the changing velocity & identifying the peak centers through each swing. The contributed biases due to these outliers is nowhere near large enough to account for the change in phase being measured (~3-5°).
Some relevant links:
- Stefan's 2019 measurement (52504)
- Stefan's 2022 measurement (66215)
- Our SRC gouy measurement from last week (92136) .
TJ, Camilla
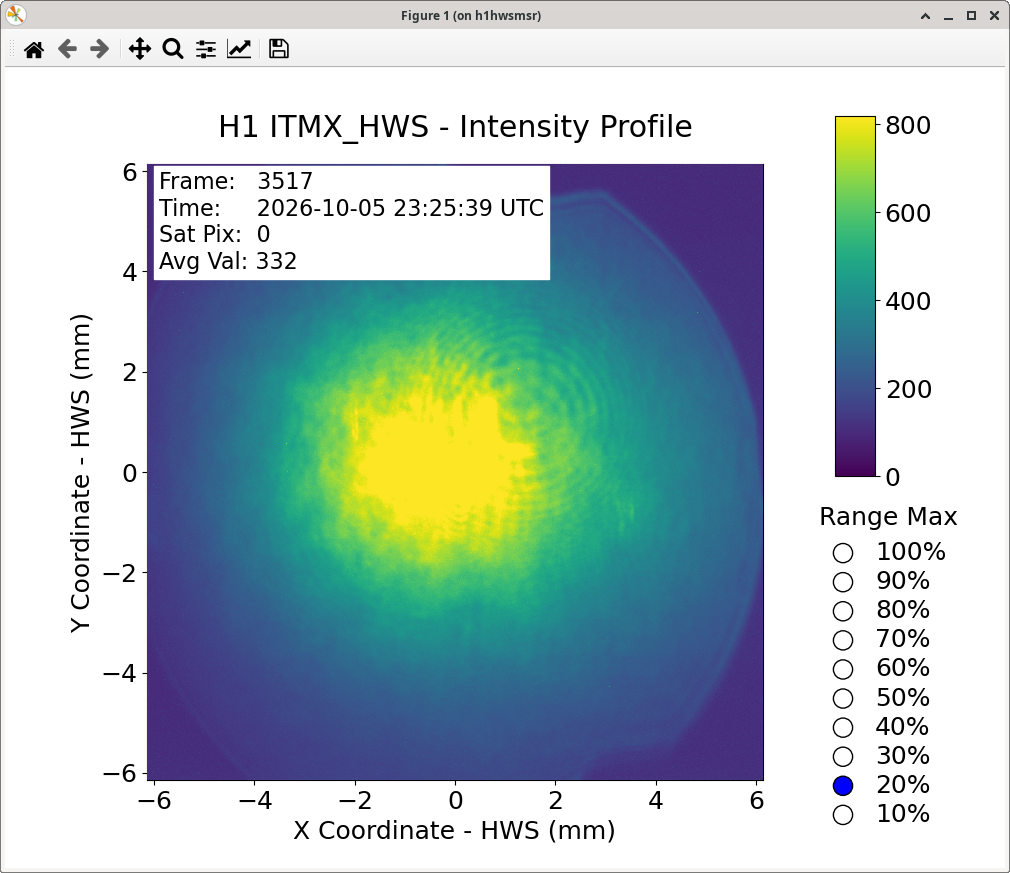
After we adjusted the HWS ITMX alignment today 92183, this evening I shuttered green, took new IX HWS references, removed some dead pixels from the camera (wiki link), and started the IX HWS code.
We are running a ring heater test with 2W/segment for 2 hours this evening. Using script below on tmux session:
Ring heaters should be back to nominal by ~11pm and fine for locking tomorrow. Purpose of this is to check HWS alignment before we align the ITMX CO2 (done for ITMY in 91616).
TITLE: 10/06 Eve Shift: 2330-0500 UTC (1630-2200 PST), all times posted in UTC
STATE of H1: Corrective Maintenance
INCOMING OPERATOR: None
SHIFT SUMMARY:
Comissioning team ran ISC_Lock up to Start_TR_CARM a few times which ended in locklosses and left it in Down for the night.
They put together an informative alog about their work that says that Initial Alignment WFS should hopfully work for input align and PRC, SRC!
Camilla is planning to make a TCS ring heater change tonight around 8. I have put her on the Reservation system for that time as well.
LOG:
| Start Time | System | Name | Location | Lazer_Haz | Task | Time End |
|---|---|---|---|---|---|---|
| 20:00 | TCS | Camilla | Remote | N | Ring heater settings change around 8PM local time | 20:30 |
Sheila, Elenna, Louis, Ryan Short, Jenne, Camilla,
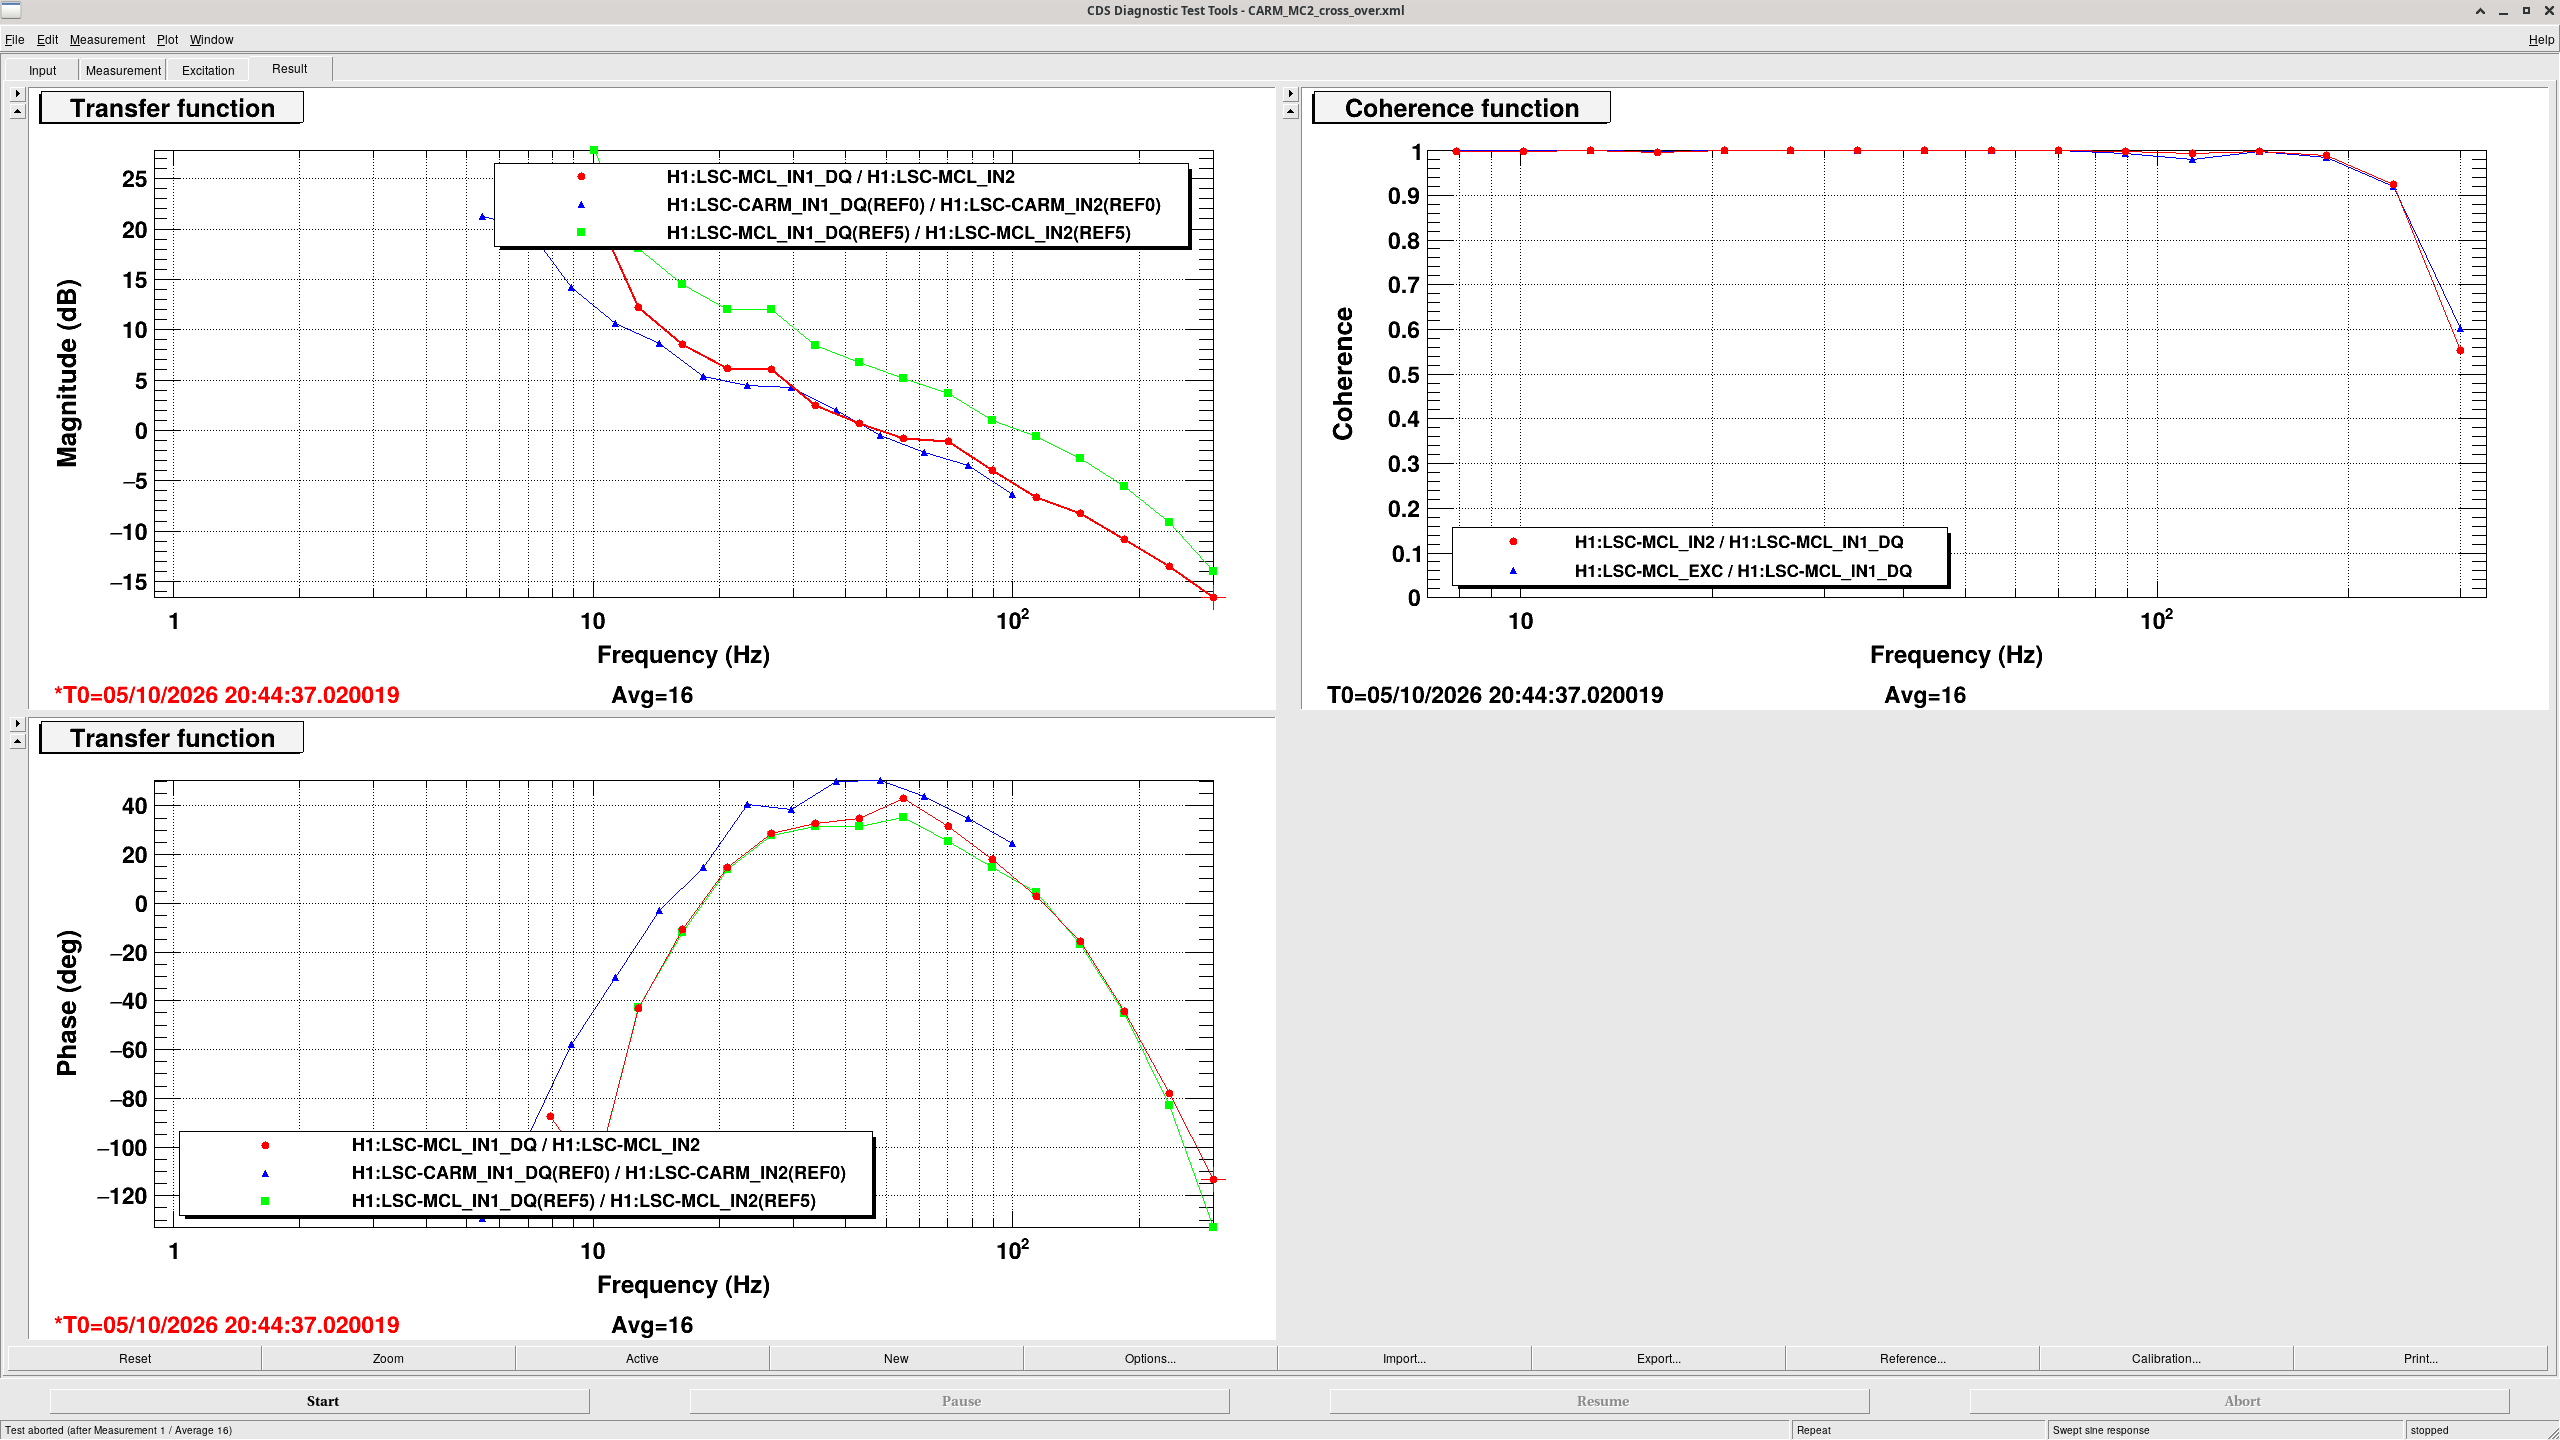
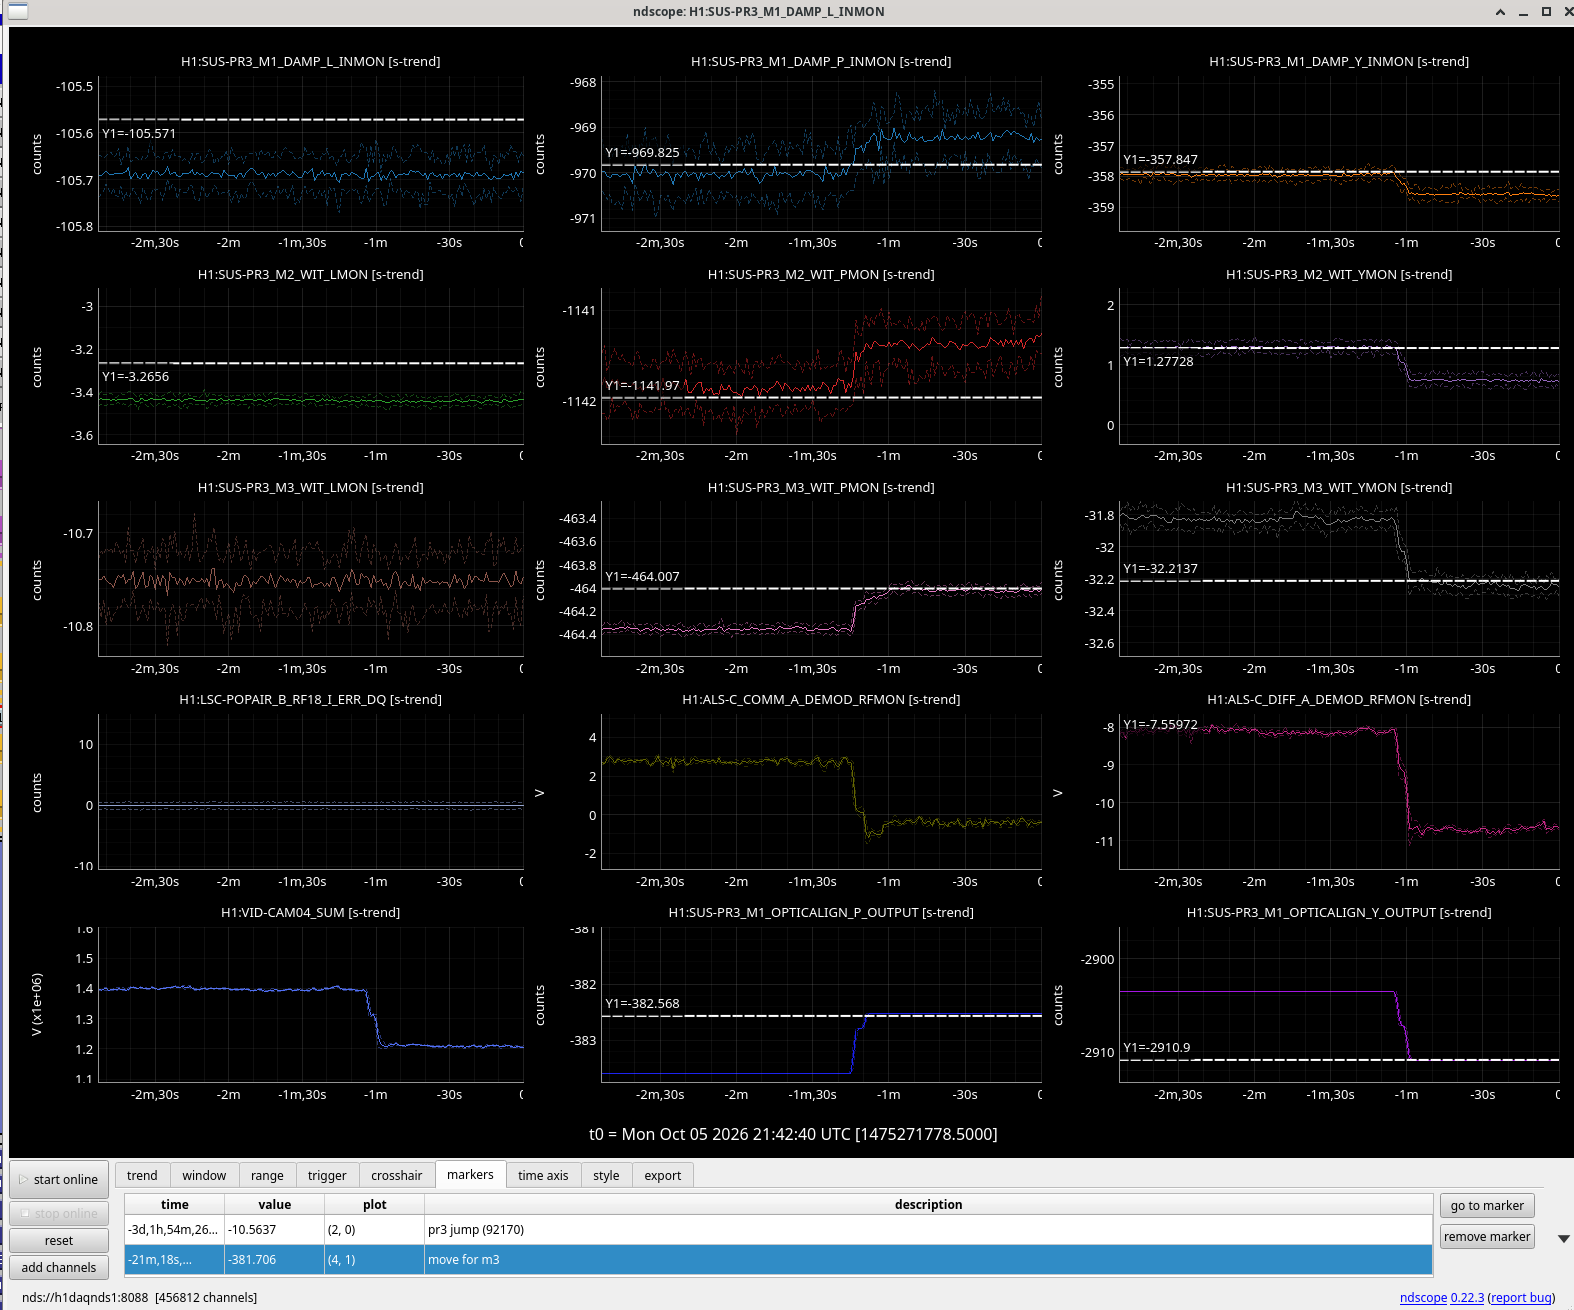
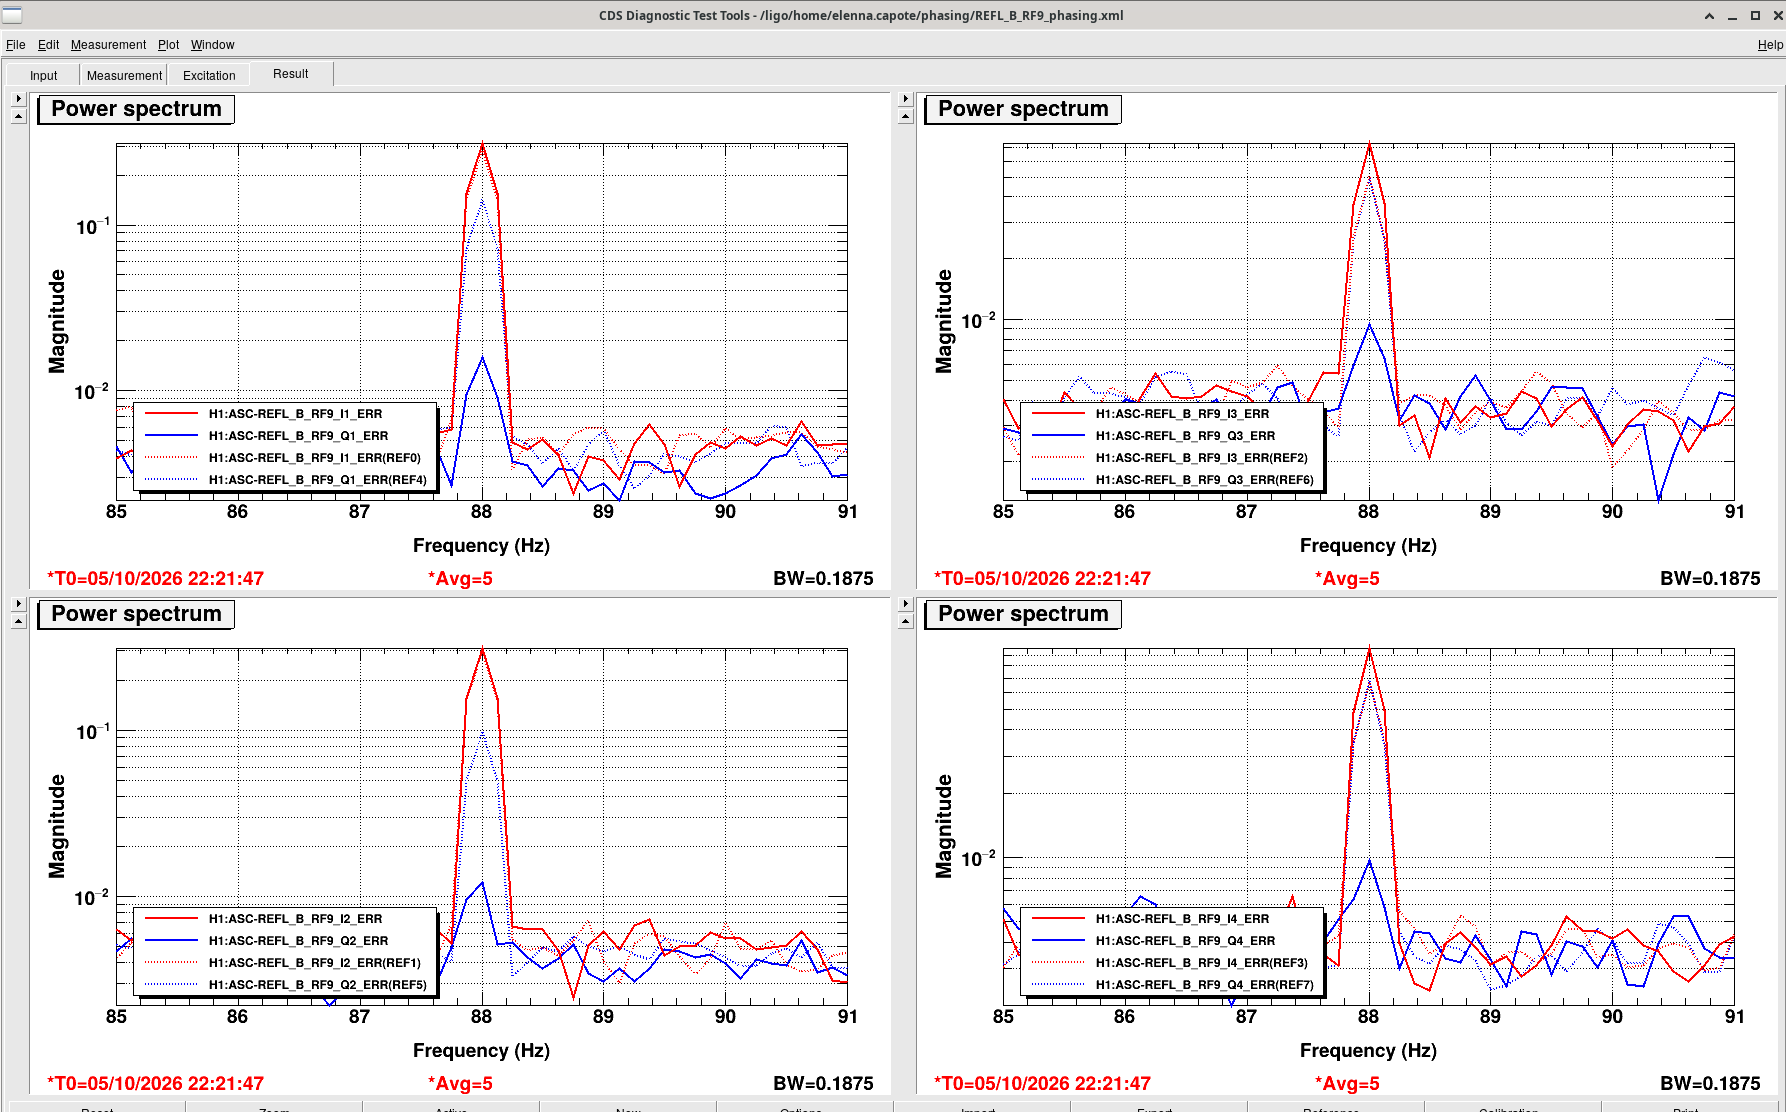
Summary: We are still struggling with DRMI mode hopping, when we get past that we are struggling with the first steps of the CARM offset reduction. We do have some initial alignment ASC working.
WP13680. TJ, Camilla
When we started, the ALS beam hit the bottom periscope mirror high.
There is circles on the CCD camera indicating dust on some optics. We inspected and found a piece of dust on the bottom periscope mirror we could n to remove. We found a spare of this mirror but have not made the decision to swap or not yet.
Moved Pico 8 which is HWS X M1. We found the edge of the beam (crooked clipped) at +500 X and +1000 Y., then fell off around -2000. Leaving at X -100, Y -1017. With just this mirror we still had a lot of baffle in the camera view.
TJ then moved the lower periscope mirror pico and could make the baffle take up less of the CCD with the beam staying well centered. Photo attached.
[Rachel Langgin and Caroline Capuano]
Rachel and I volunteered to check if the alignment flucations were any worse than before IR1 upgrades (see commissoning meeting notes). To compare this, we check during O4c (gps 1444003218, October 9th, 2025) as our reference time and compared this spectrum with our most recent data from Tuesday (gps 1474675218, September 29, 2026) when everything was quiet. The script we used to make these plots can be found here.
Please keep in mind that this is comparing the old beam splitter to the new beam splitter so the change you see here could be related to that. This comparison can be re-run once we are locked for a more accurate comparison.
Optics_ASD_1444003218_vs_1474675218.pdf shows the ReferenceTime and CheckTime on the same figure for each optic, and Optics_ASD_1444003218vs1474675218-2.pdf shows the ratio between the two spectrums; both of these have a 60 second time span. Most of the optics do agree at higher frequencies, but a lot of them show differences in optics motion at low frequencies. Some optics shows some major motion differents below 10 Hz, like PRM, RM1, RM2, OM1 pitch and yaw, OM3, OMC.
Update:
Below are plots with a longer time span (10 minutes) and fft length of 64, and a different check time as well:
TITLE: 10/05 Day Shift: 1430-2330 UTC (0730-1630 PST), all times posted in UTC
STATE of H1: Corrective Maintenance
INCOMING OPERATOR: Tony
SHIFT SUMMARY: Majority of the day was spent commissioning the mode hopping problem in DRMI and some work towards moving past TR_CARM (commissioners will post their own alog with the details). The LVEA is also Laser HAZARD for HWS table work.
LOG:
| Start Time | System | Name | Location | Lazer_Haz | Task | Time End |
|---|---|---|---|---|---|---|
| 14:55 | FAC | Kim | Optics Lab | - | Technical cleaning | 15:15 |
| 15:15 | FAC | Kim | MX | - | Technical cleaning | 16:38 |
| 16:15 | PEM | Fil | OSB Roof | - | Checking anemometer | 17:27 |
| 17:14 | TCS | Camilla | Prep Lab | - | Grabbing cable | 17:29 |
| 17:52 | EE | Fil | MY | - | Picking up cables | 18:26 |
| 18:00 | TCS | Camilla, Sophie | Prep Lab | - | CHETA table work | 18:16 |
| 19:57 | PEM | Miranda, Alex | MER | - | Looking at PEM kits | 20:05 |
| 20:06 | TCS | Camilla, Sophie | LVEA | - | Checking CHETA cables | 20:22 |
| 20:26 | TCS | Camilla, Gerardo | Prep Lab | - | 21:10 | |
| 20:33 | ISC | Keita, Alex | LVEA | - | OMC function generator changes | 20:40 |
| 20:44 | SEI | Jim, Jennie | CER | - | Checking SPI chassis wiring | 20:50 |
| 22:01 | SAF | TJ | LVEA | Y | Transitioning to Laser HAZARD | 22:12 |
| 22:12 | TCS | TJ, Camilla | LVEA | Y | HWS table alignment | 00:12 |
| 22:37 | TCS | Sophie | Prep Lab | - | Quick measurements | 22:52 |
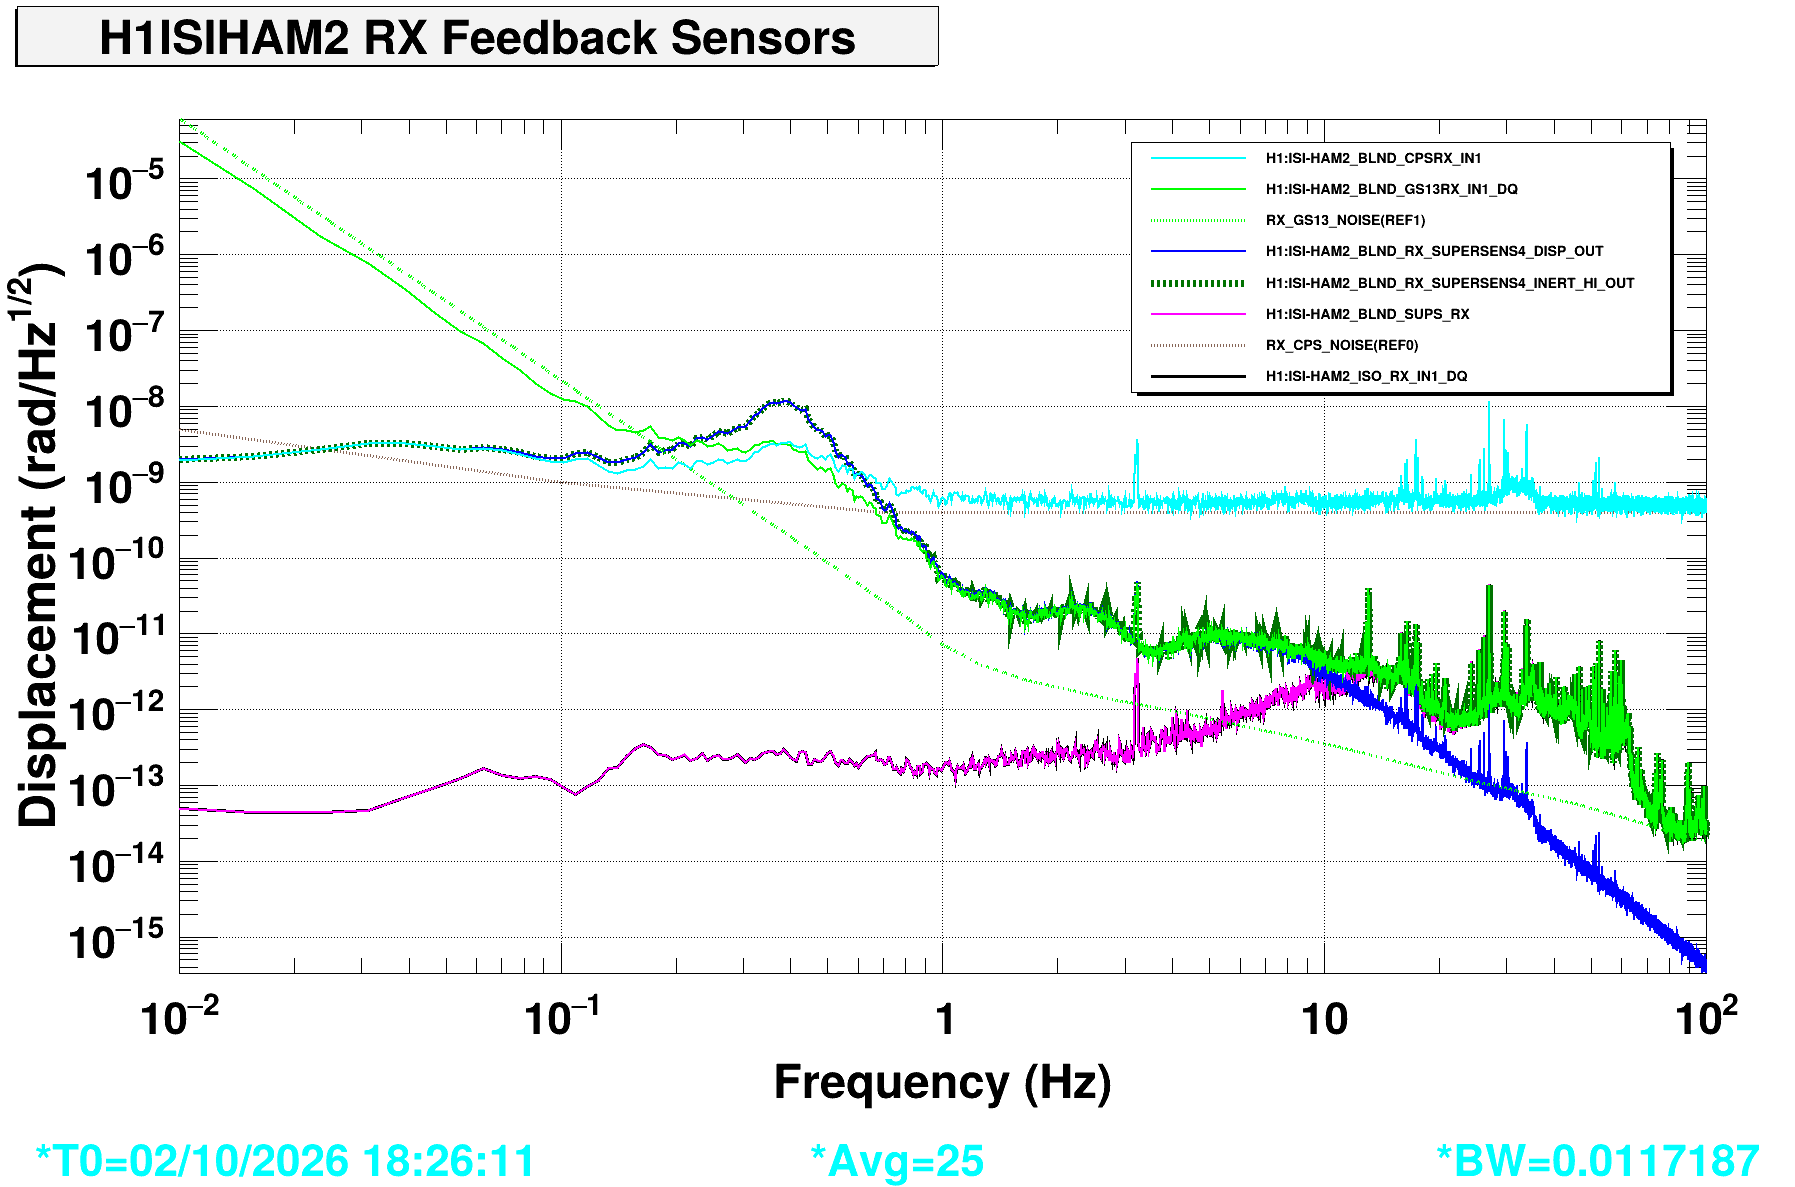
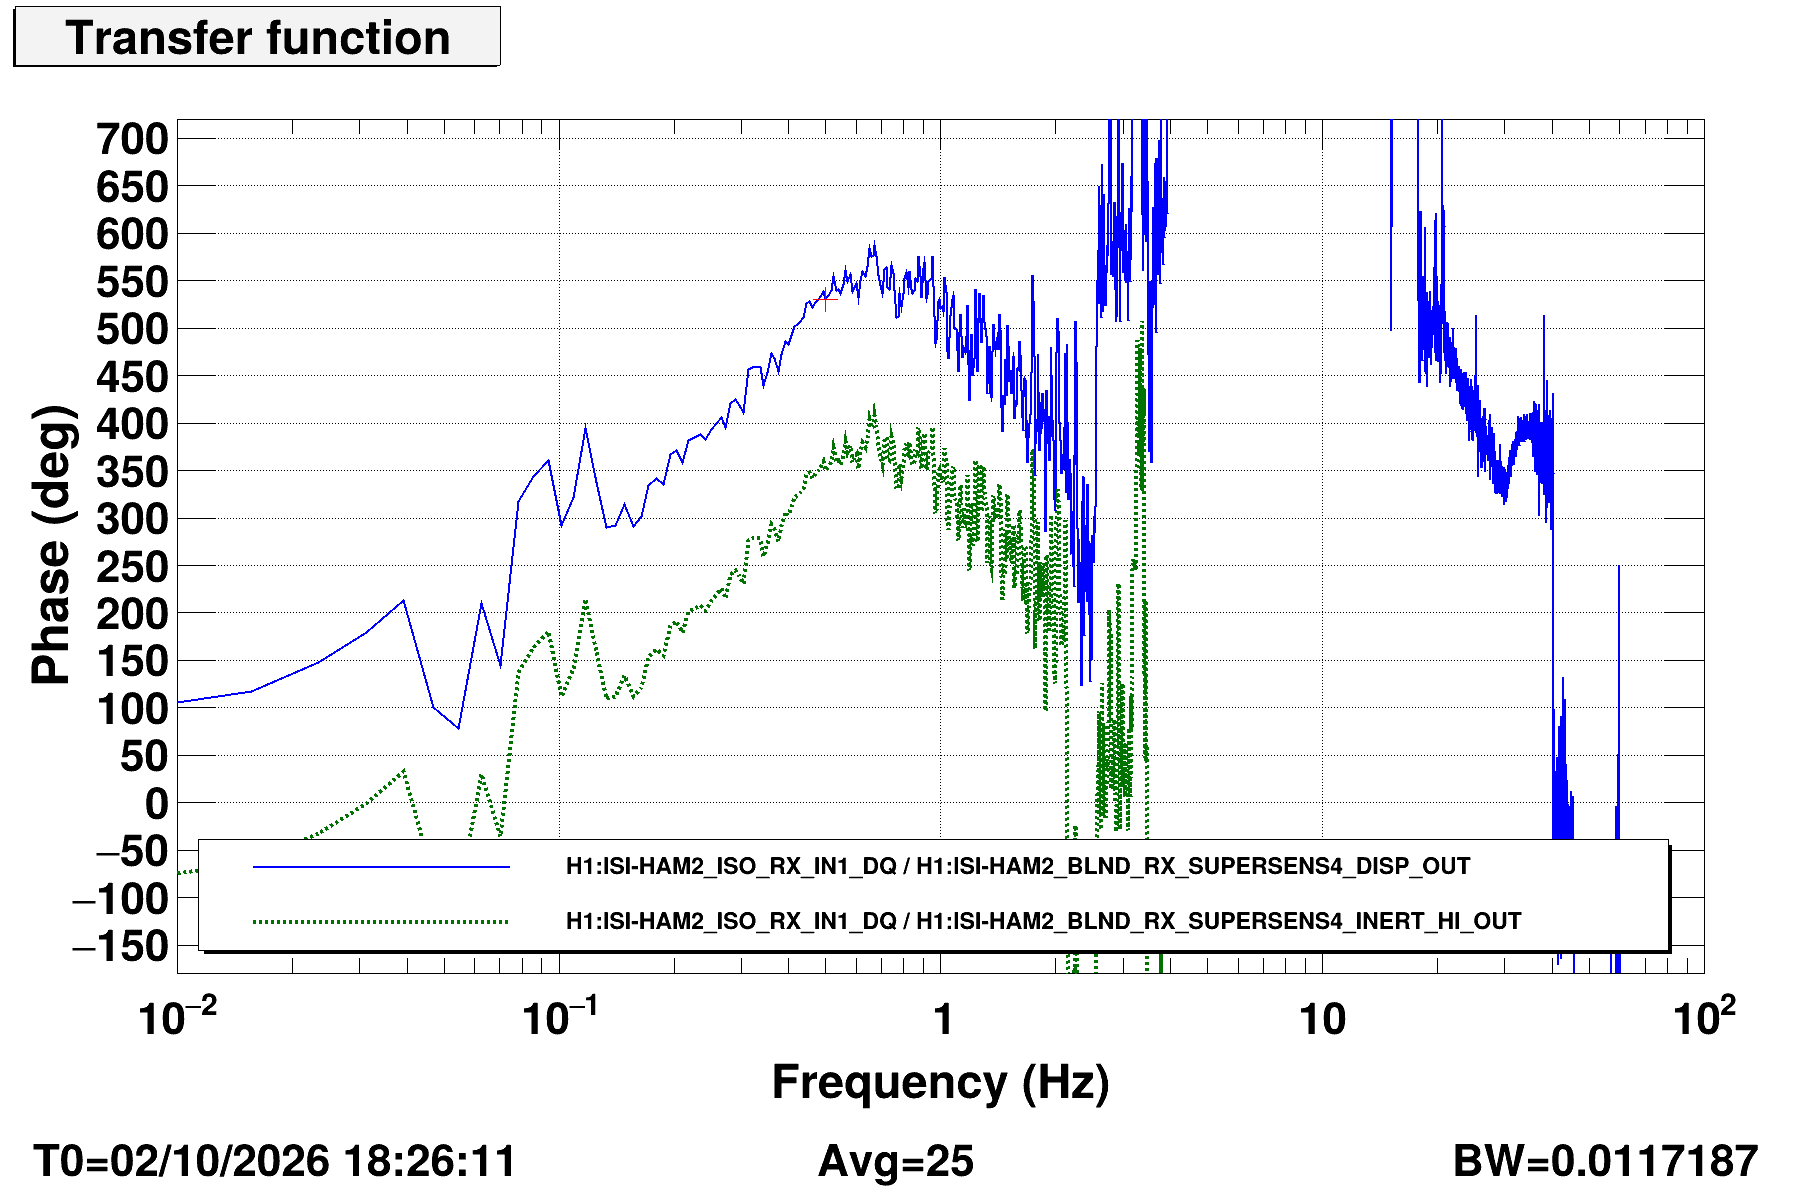
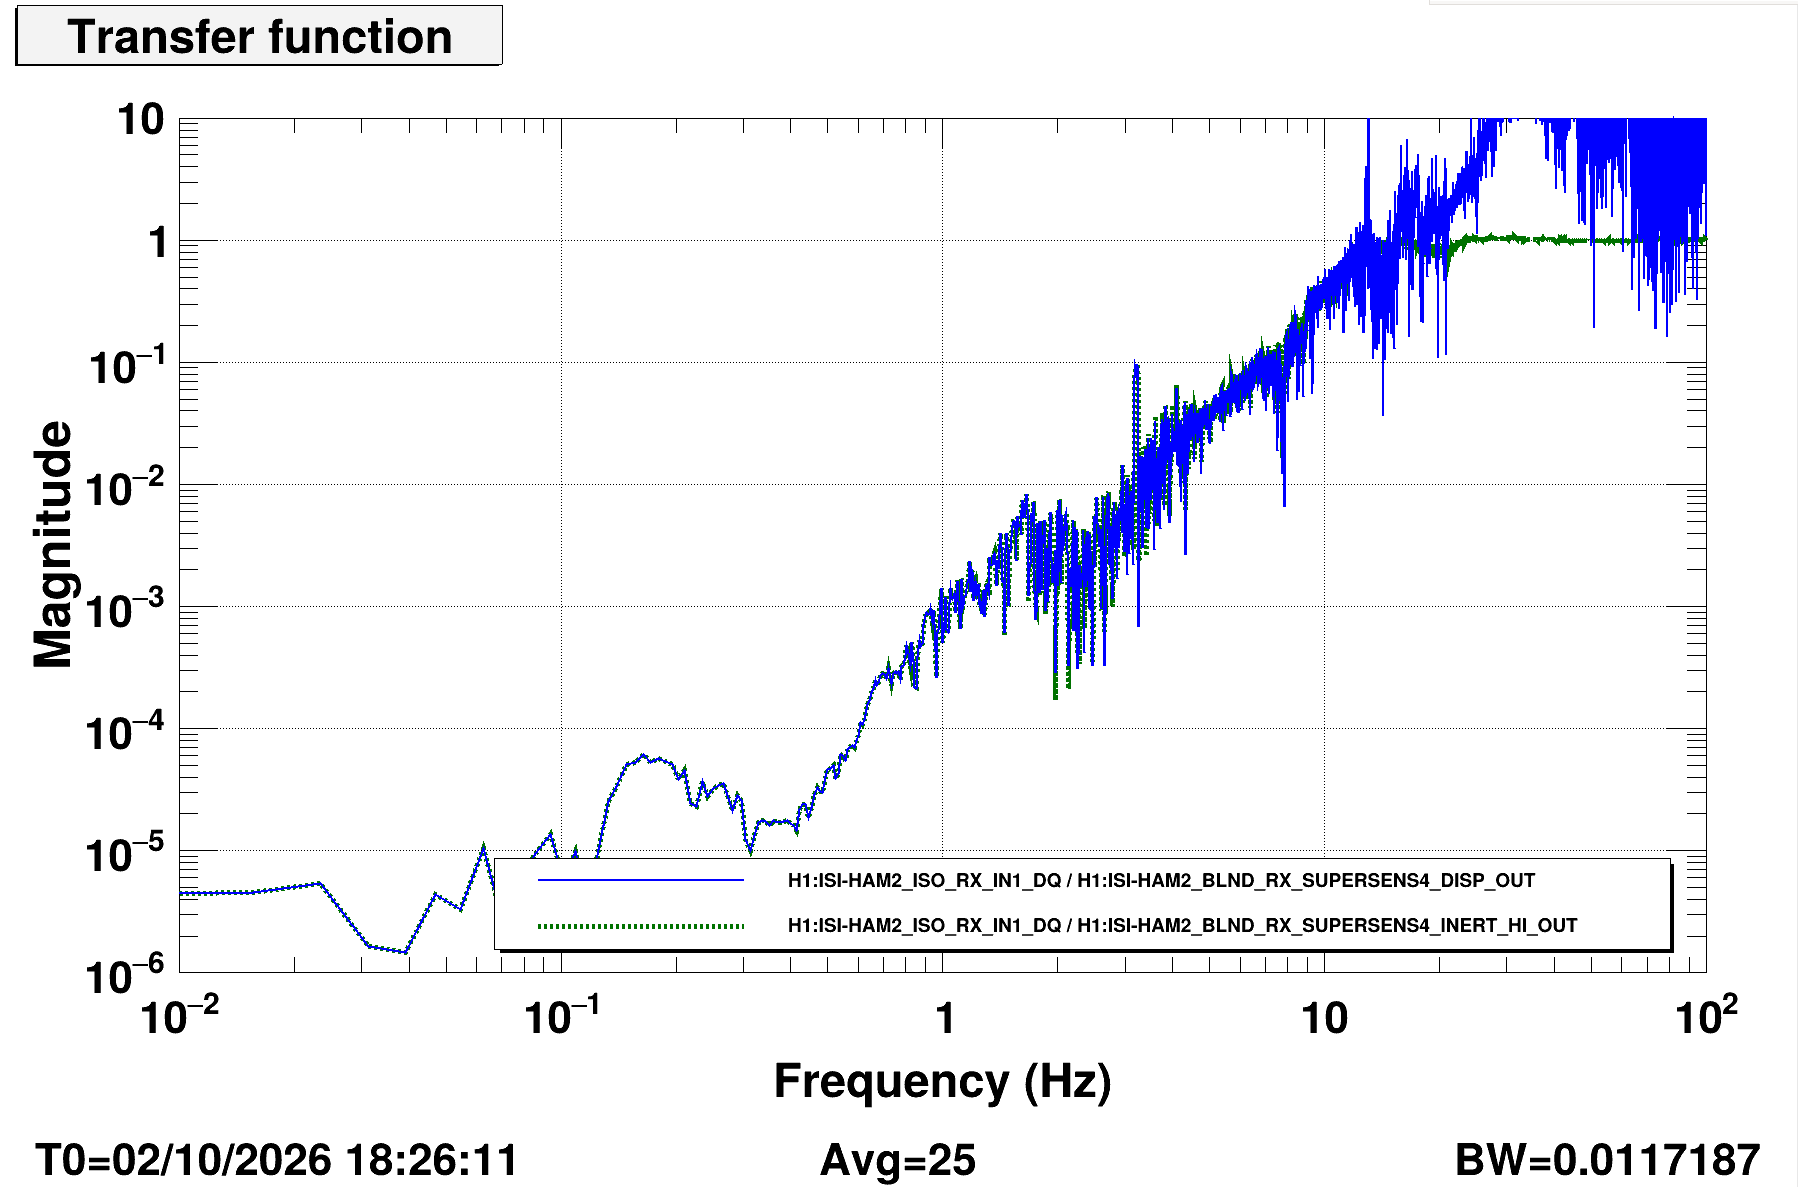
J. Kissel As we explore the relationship between HAM3 - HAM2 differential motion with the SPI, it's forcing us to re-understand some ISI fundamentals. Brian made claims that we *shouldn't* use the ISI super sensors as metrics for the real displacement of the platform in LHO:92129, and points us to some math in T2500279. I wanted to back up the math with some plots of platform motion to help better visualize the math. You can find plots of the current blend filters in use, in their dimensionless comparable form, from LHO:70527. - the X/Y blend frequency is 0.18 [Hz] with broad gain peaking of around 1.5x to 2x from 0.03 - 0.6 [Hz]. - the RX/RY blend frequency is 0.375 [Hz] with more focused gain peaking of 4x from 0.1 to 1 [Hz]. Let's start with RX, since that's a relatively simple feedback loop, with no sensor correction complicating the math. (RX-1) RX ASD (Blend Inputs vs. Blend Outputs vs. Super Sensor) - The input to the blend filters are shown in SOLID light blue (CPS) and green (GS13), compared with their sensor noise scaled to the RX degree of freedom (same color, just in dot-dot line style). Above ~1 Hz, the CPS is limited by its sensor noise, but also arguably below 0.1 Hz. Below 0.15 Hz, the GS13 is limited by its sensor noise. This implies that - As we apply the blend filters to those input signals, we see what Brian describes in Section 2 of his document: . There's a hefty amount of gain peaking between 0.1 and 1 Hz [Hz] from the complementary blends, reporting a factor of ~4x more motion than at the input. . The CPS output is virtually identical in amplitude to the GS13 output up to 10 Hz. . The sum of the two blended outputs is "essentially zero" -- this is what we strive to understand. - There two channels, H1:ISI-HAM2_BLND_RX_FADE_OUT and then H1:ISI-HAM2_BLND_SUPS_RX -- test points in series just after the sum -- and just downstream's H1:ISI-HAM2_ISO_RX_IN1 that are equivalent and identical. These two test points being identical to the ISO input is only true for DOFs where there's no input from the SUSINF external "sensor correction," either SUS offloading or CPS DIFF or SPI, as is true for the RX DOF -- knowing this will become important for DOFs that employ, e.g. CPS DIFF like the X DOF. I show the SUPS_RX and ISO_RX_IN1 channels here just confirm that there's nothing wild or crazy going on like "the signal changes as you exit up and out of a level in the simulink model," and to show that there's no external input from SUSINF. (RX-2) RX TF COH (Blend Outputs vs. Super Sensor) - This shows the linear coherence between each output to the blends and the super sensor. - assertion The CPS output's coherence is only non-zero where the CPS are actually measuring real platform motion where that signal appears above the sensor noise, between 0.1 and ~1 Hz. - The coherence of the GS13 output matches the coherence of the CPS below 10 Hz. assertion That implies that the GS13s are measuring the exact same thing as the CPS in this frequency region, whether it be real platform motion, or CPS sensor noise * the blend CPS filter. (RX-3) RX TF PHA(Blend Outputs vs. Super Sensor) - This shows the (unwrapped) phase of the TF between the CPS blended output and the GS13 blended output w.r.t. the super sensor. - At least below ~3 Hz [Hz] it's obvious that the blended output of the CPS is exactly 180 [deg] out of phase with the blended output of the GS13 Spot check of RX TF Phase at 0.5 [Hz] DISP OUT / SS = 529.8 [deg] INERT OUT / SS = 349.8 [deg] Difference = 180 [deg] One can only trust the spot check at most frequencies if the blend filters are truly complementary. If they're not, then you've gotta be conscious of the "deviation from complementary" in the comparison. This will become important for DOFs where we push hard on the performance, like the X DOF. - Thus, the two signals, measuring exactly the same thing with the same amplitude below ~10 Hz, and when added together, given their phase relationship, you get a super sensor signal that's "essentially zero." (RX-4) RX TF MAG (Blend Outputs vs. Super Sensor) - This shows magnitude of the TF between the CPS blended output and the GS13 blended output w.r.t. the super sensor. - Again, below ~10 [Hz], the GS13 and CPS blended outputs has the same transfer function magntiude w.r.t. the super sensor. - This -- especially is essentially a measure of the loop suppression - assertion where the TF is incoherent, the TF magnitudes loop suppression is reporting that the platform motion is dominated by suppressing sensor noise. In the case of the GS13s, its an independent measure of this loop-suppressed CPS noise that's dominating the platform motion.
TITLE: 10/05 Day Shift: 1430-2330 UTC (0730-1630 PST), all times posted in UTC
STATE of H1: Corrective Maintenance
OUTGOING OPERATOR: None
CURRENT ENVIRONMENT:
SEI_ENV state: CALM
Wind: 4mph Gusts, 2mph 3min avg
Primary useism: 0.01 μm/s
Secondary useism: 0.11 μm/s
QUICK SUMMARY: H1 in IDLE over the weekend; I'll start running some alignment to prepare for the day of locking progress. Found OM3 saturating, so I'll look into backing that off a bit.
In loop from 10/03 05:00 UTC (but only analyze from 05:30 UTC) to evaluate stability and possible tilt improvement from lower noise floor.
Had to reduce damping gain from 1 to 0.01, it looks like it was otherwise fighting with the isi loop.
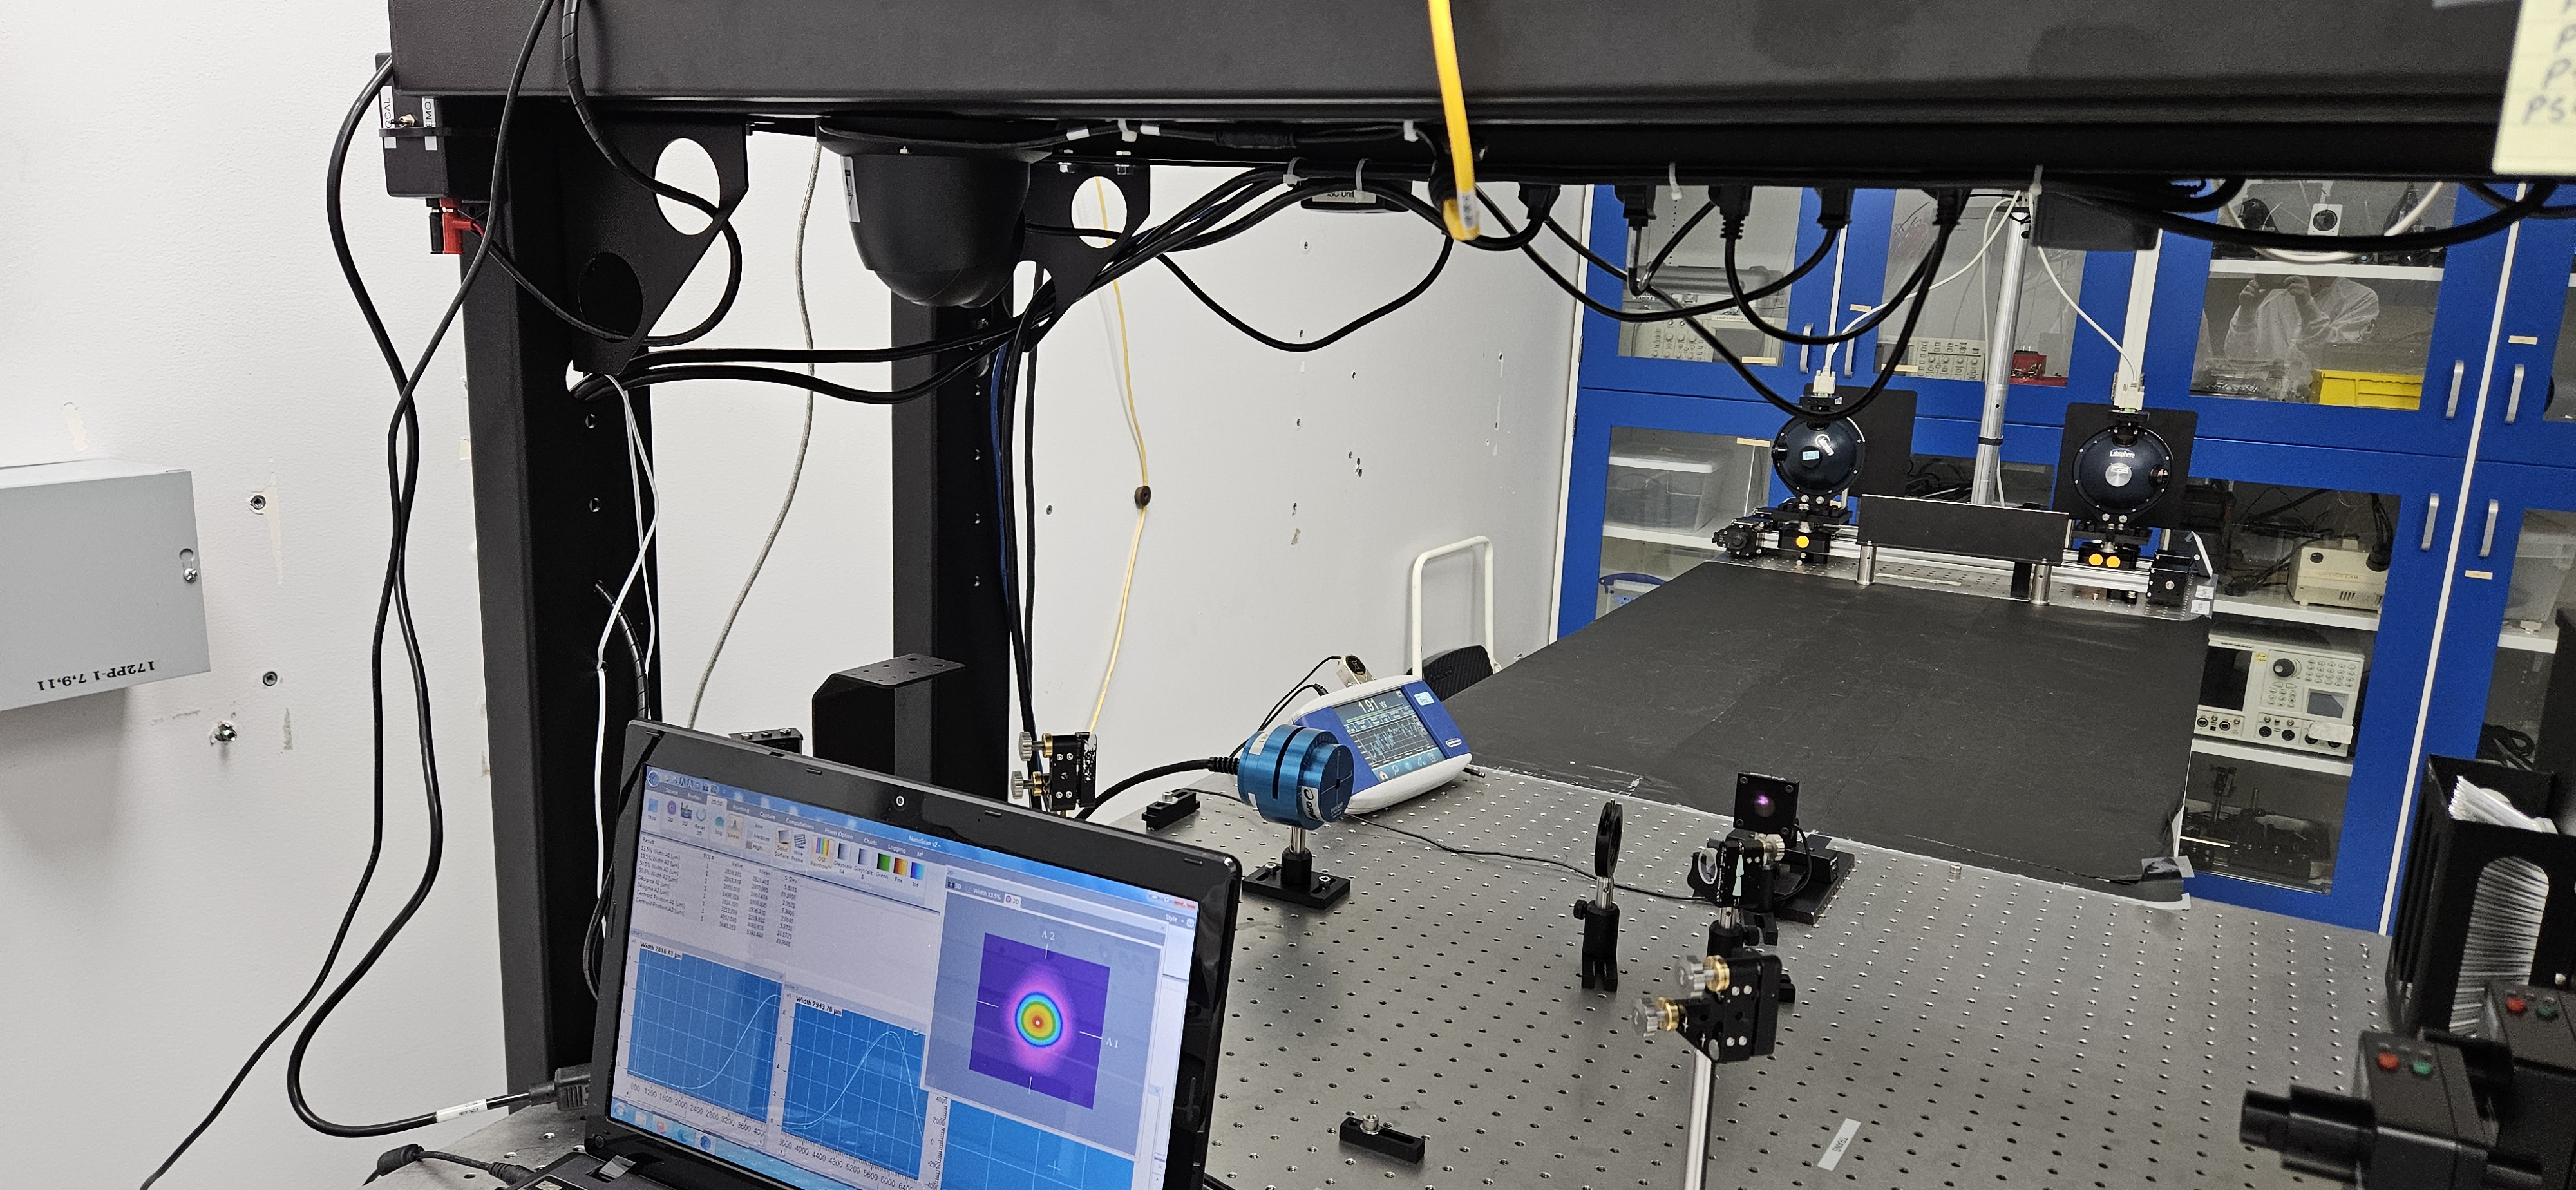
I've been in and out of the PCAL lab trying to test this new laser from CrystaLaser this week.
Thankfully I was able to connect with Dr. Jin out there and they steered me in the right direction.
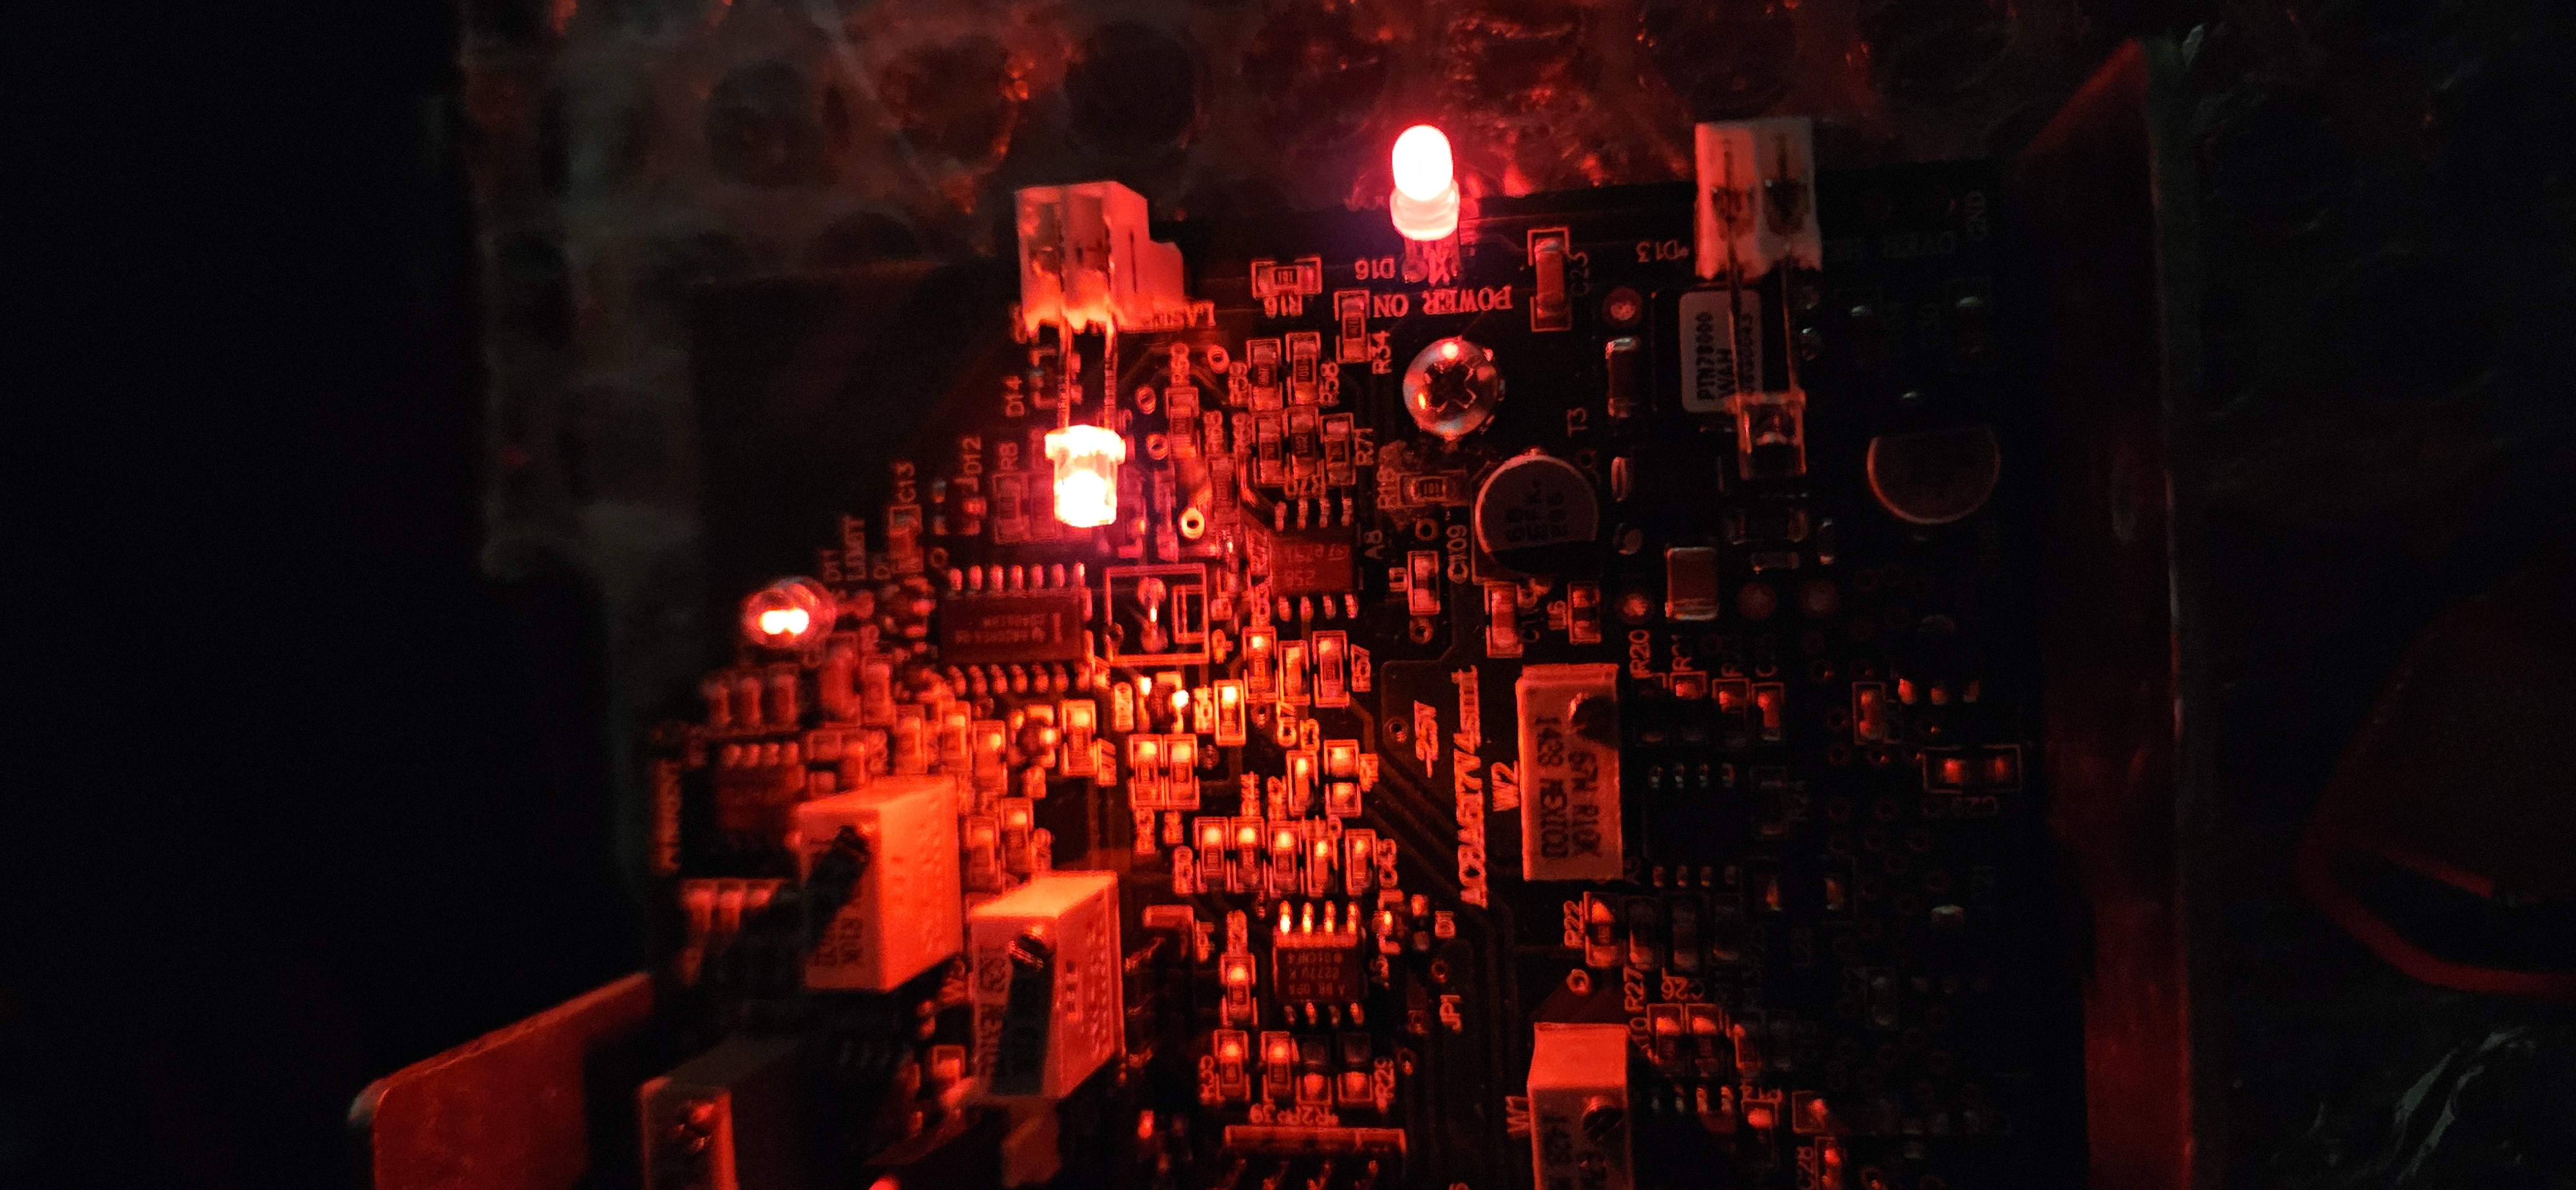
When I first tried to test it I had the wrong power supply that couldn't keep up with current demands. As noted by the faintly lit current limit LED. The laser needs around 1.3 to 1.5 Amps to start up.
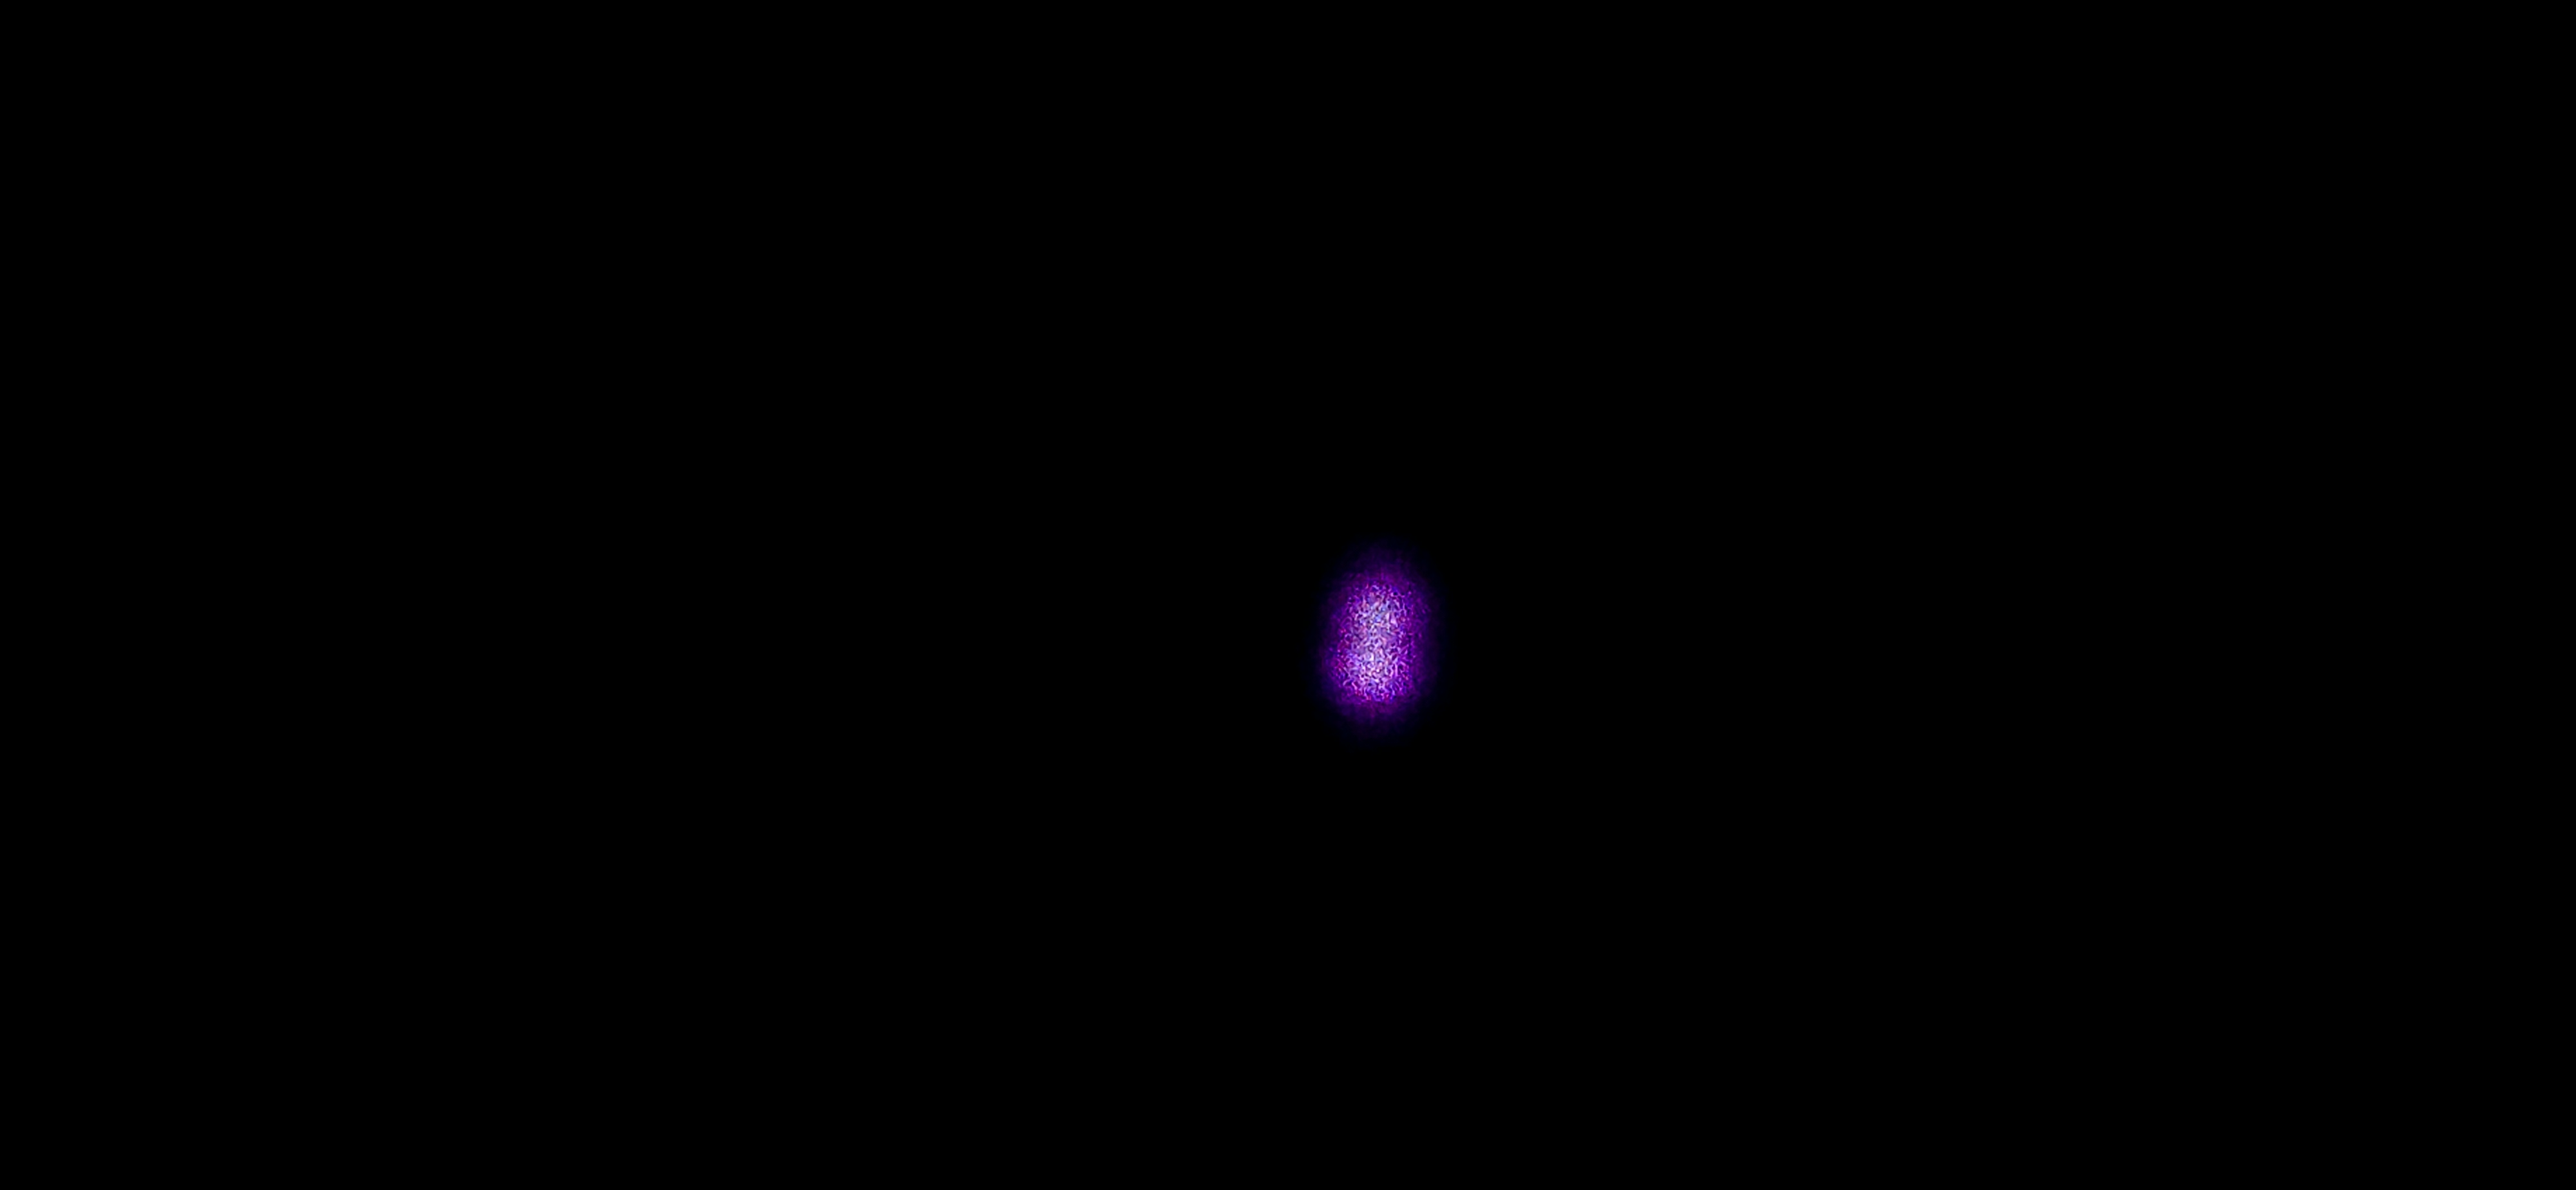
I've been finding that I had a fairly consistant TEM01 mode coming out of the laser it's self. I'm certain that the laser's been jostled around during shipping. After a few emails with Dr. Jin about this, Jin was able to guide me towards easily tweaking the laser to get a much better beam out of this laser head.
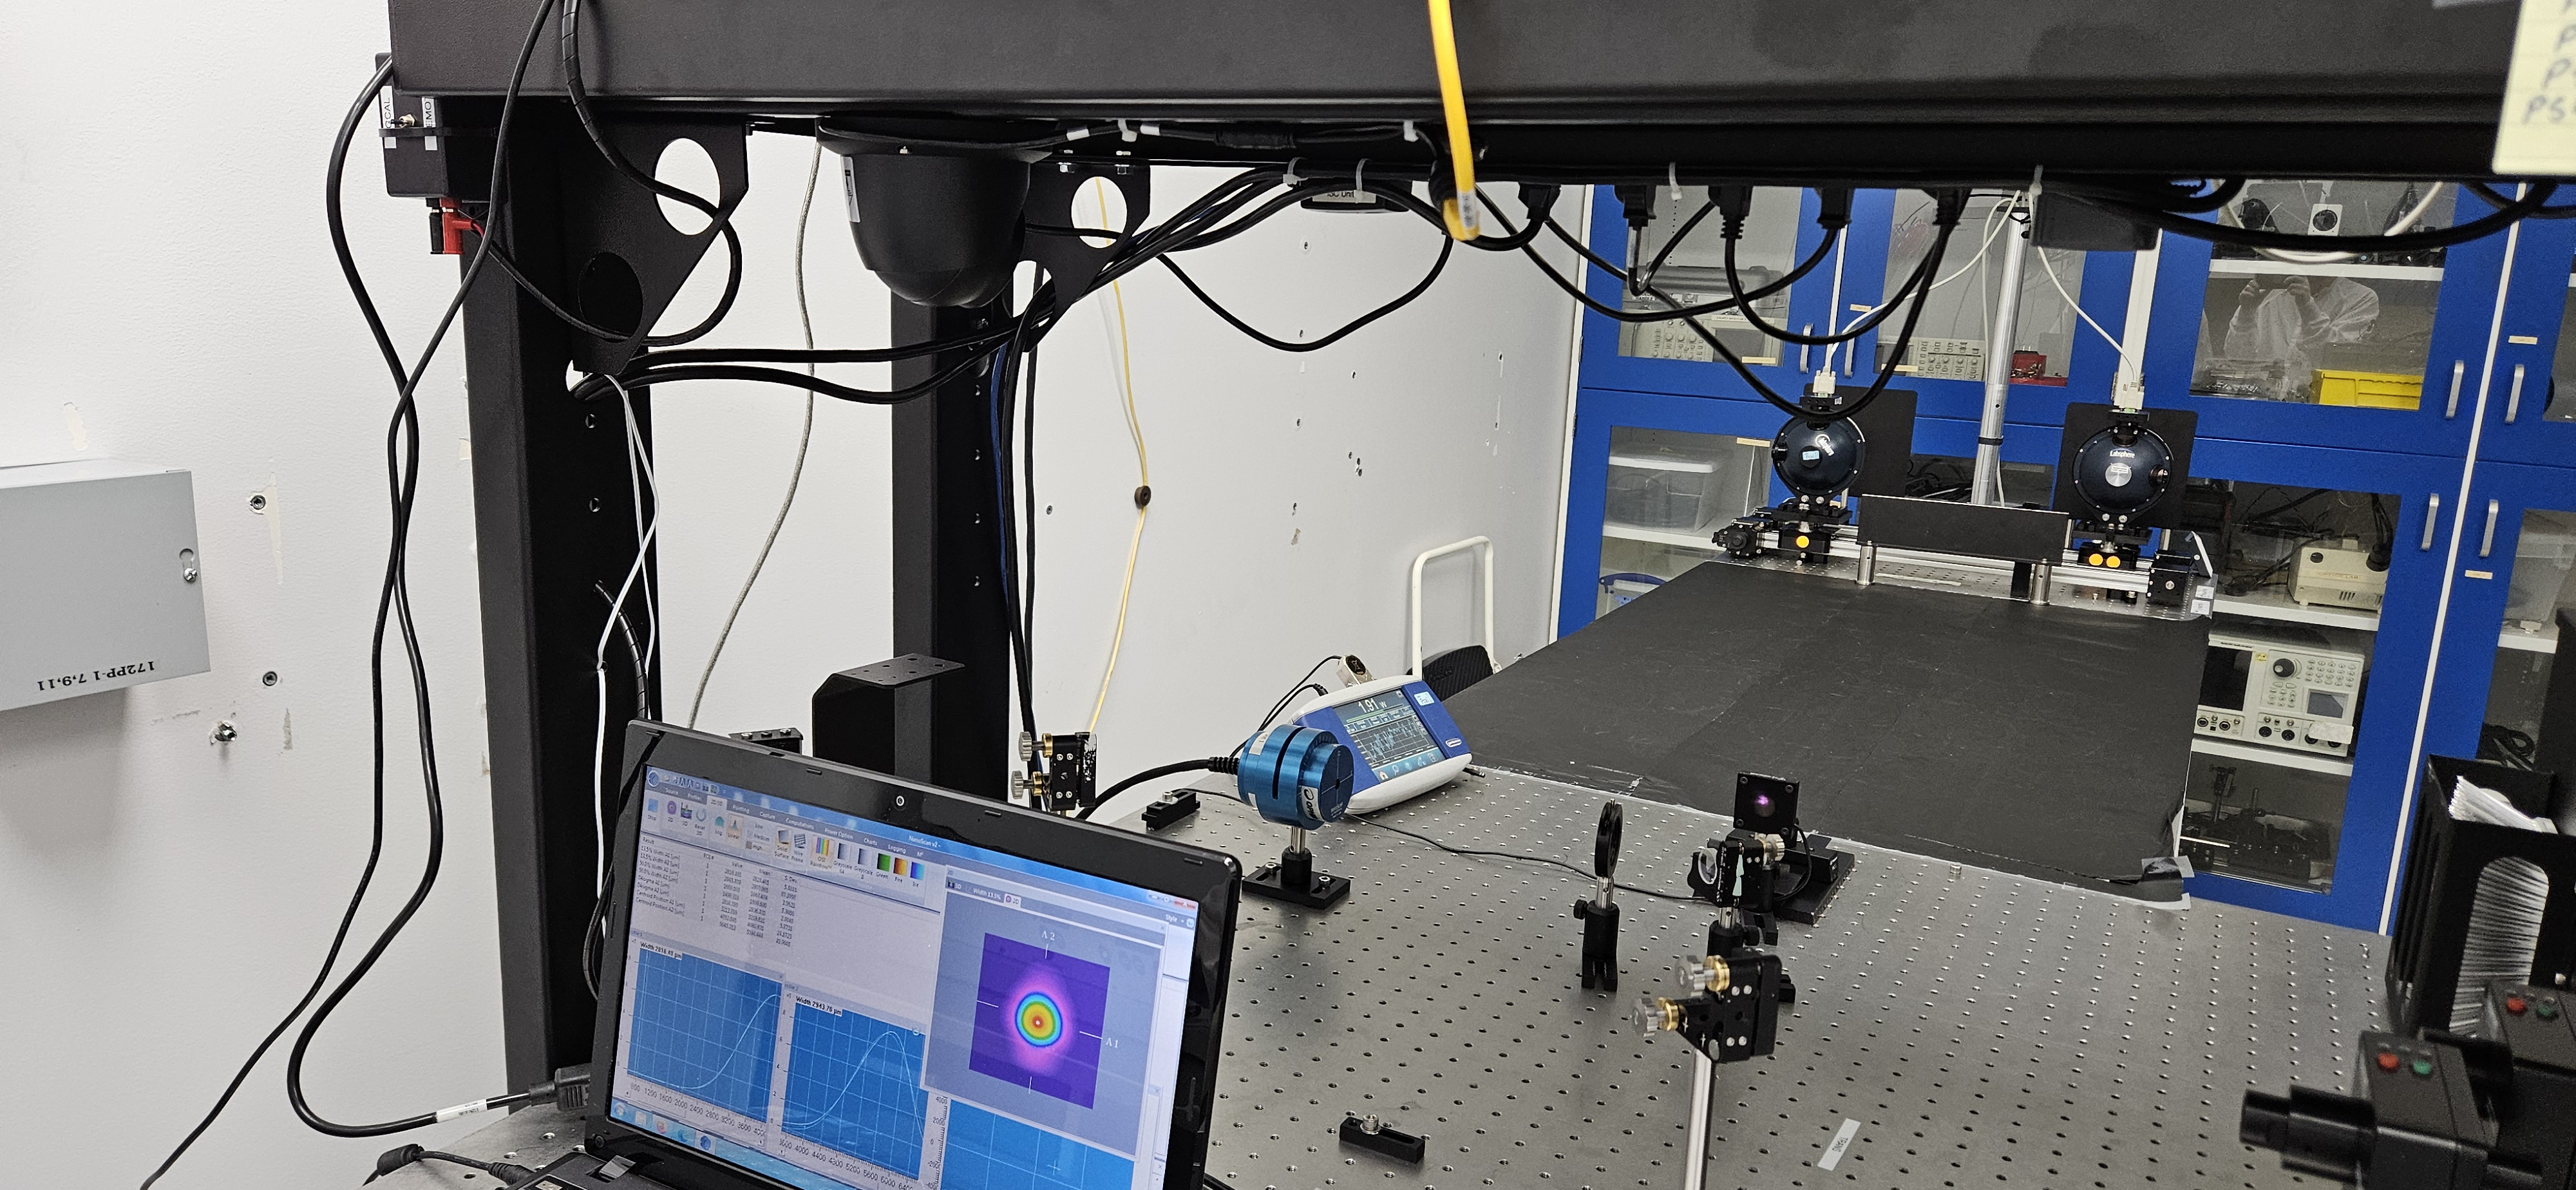
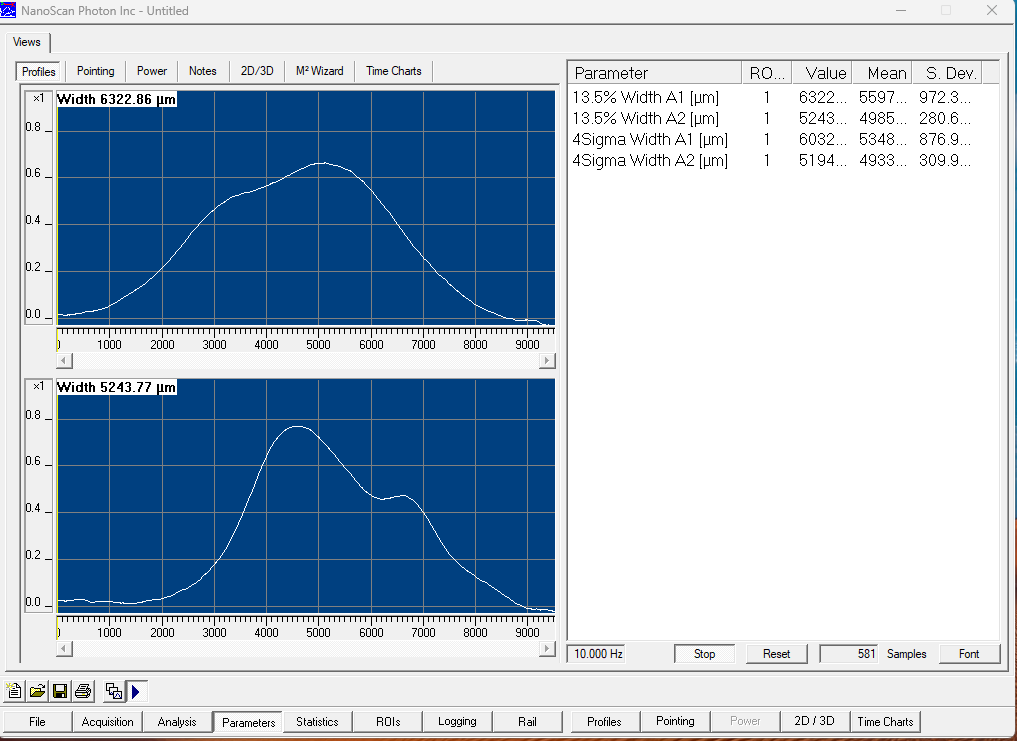
I was able to set up a beam profiler to do some preliminary beam profile data from a scanning slit profiler that was getting 1% of the beam out of a 1% beam splitter.
the other 99% was sent to a power meter.
Subject laser:
Make: CrystaLaser.
Model: CL1047-2W0-ULG
Serial number: SN 460308-9464
Gov #: G33348
Max power: 1.92W (measured after a 1% beam spliter.)
More beam profiler info comming soon.
TITLE: 10/03 Eve Shift: 2330-0500 UTC (1630-2200 PST), all times posted in UTC
STATE of H1: Corrective Maintenance
INCOMING OPERATOR: None
SHIFT SUMMARY: We're still having trouble at TR_CARM. There was some weirdness with PR2 then SRM, I'm leaving IFO in down for the weekend.
LOG:
| Start Time | System | Name | Location | Lazer_Haz | Task | Time End |
|---|---|---|---|---|---|---|
| 00:09 | CDS | Tony, Erik | H2 | N | Front end test setup | 00:34 |
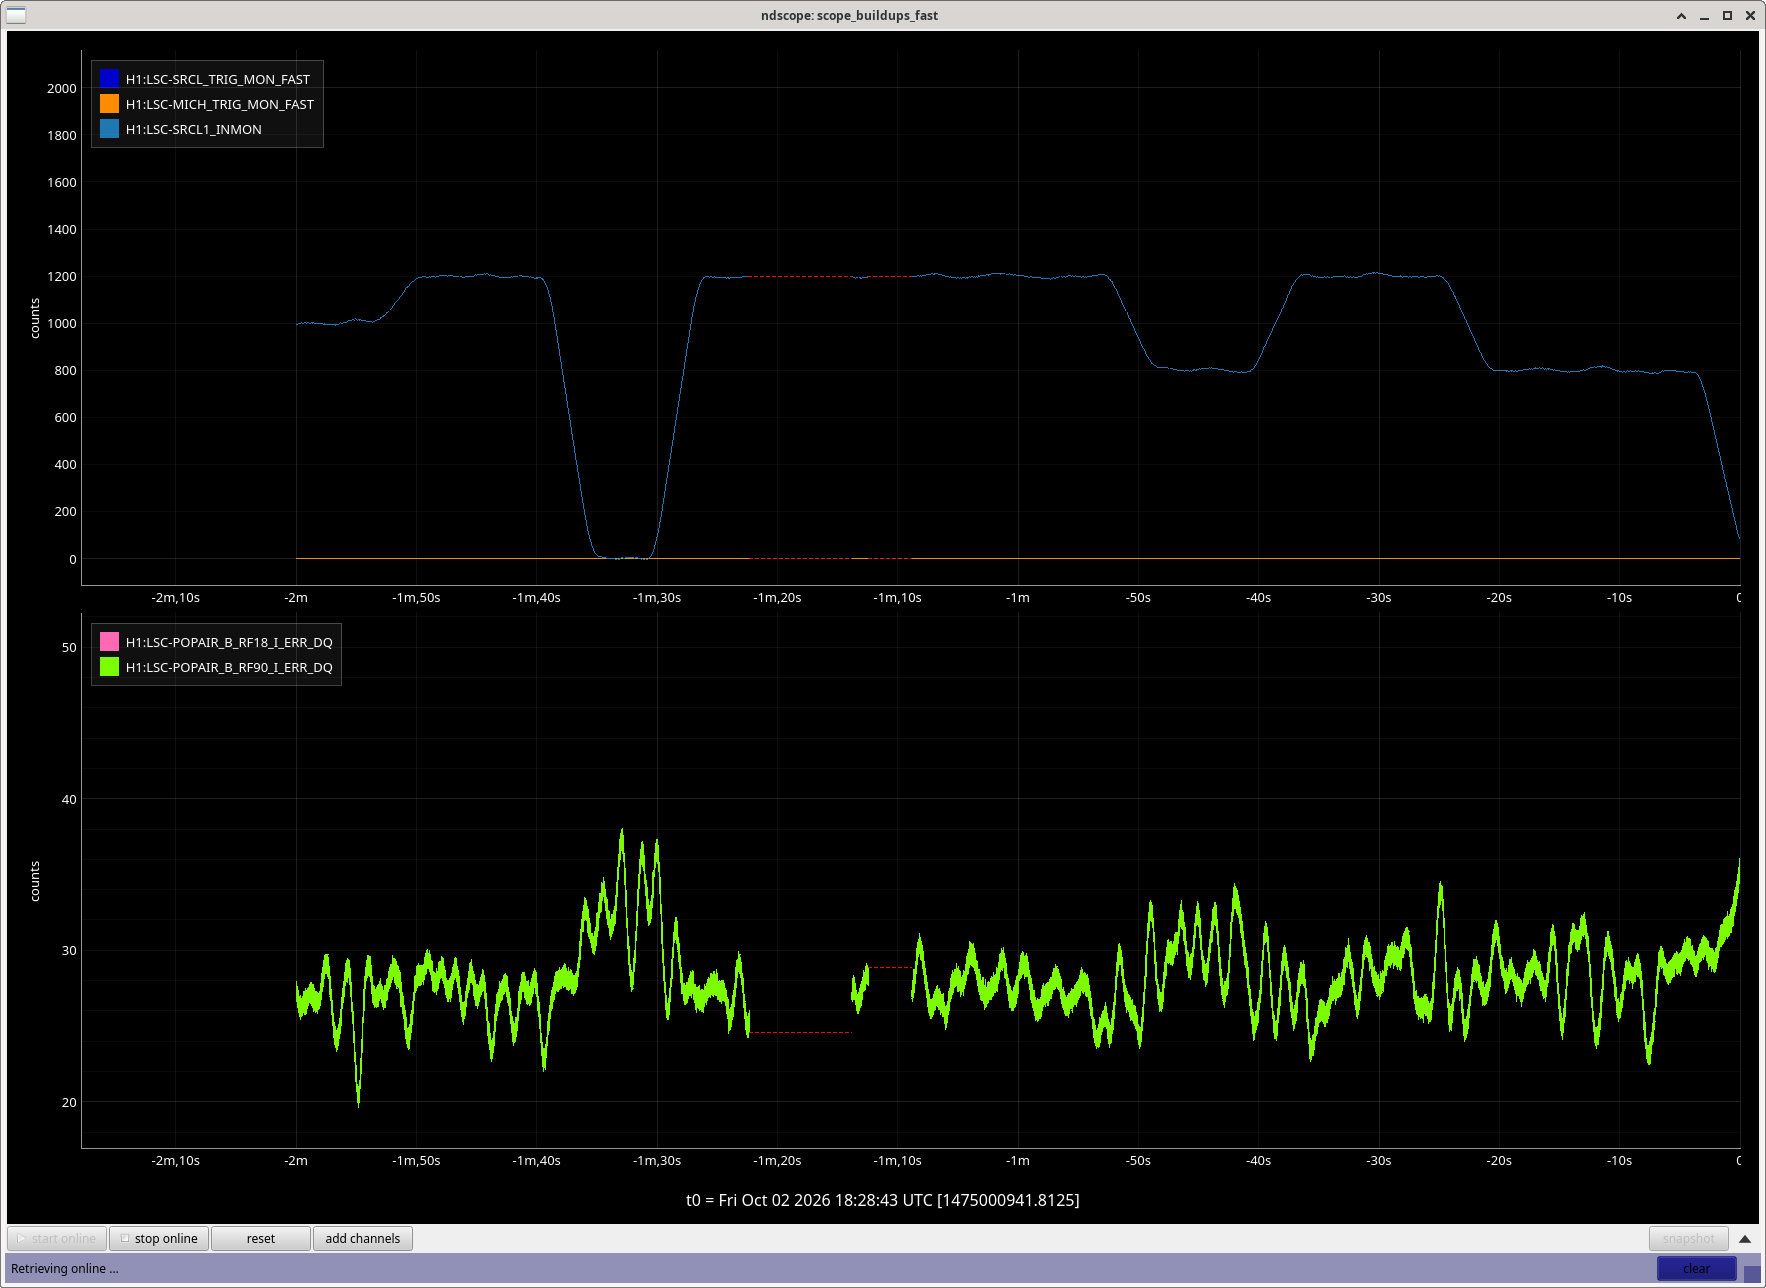
~23:30 UTC While I was locking DRMI to then touch up SRM, after doing the same for PRMI and PRM, all of M3 and M1 LF RT immediately saturated with a huge signal coming from ISC L. Looking at the LSC SRC1 filter bank, we could see that the error signal could not reach positive 800 due to the offset of -800. Keita then turned off FM4 and the saturations stopped, turning it back on brought them right back. We were able to turn that filter off and on while seemingly remaining locked (if it was a real lock, heres a plot of the sidebands power during PRMI then the subsequent DRMI, the levels are about the same) on DRMI 1f despite having no length feedback. The SRM alignment was likely bad, it "held" until I manually brought us down with ISC_LOCK.
TITLE: 10/02 Day Shift: 1430-2330 UTC (0730-1630 PST), all times posted in UTC
STATE of H1: Corrective Maintenance
INCOMING OPERATOR: Ryan C
SHIFT SUMMARY:
Today there was continued work looking at the lead-up to the CARM TO TR step for ISC LOCK. For the most part DRMI reacquisition was fairly easy (Sheila alog-ed about a random PR3 move which was odd.)
Toward the end of the shift, OM3's heater was increased from 1.0 to 4.0W for over the weekend.
LOG:
Daniel, Sheila, Corey, Keita
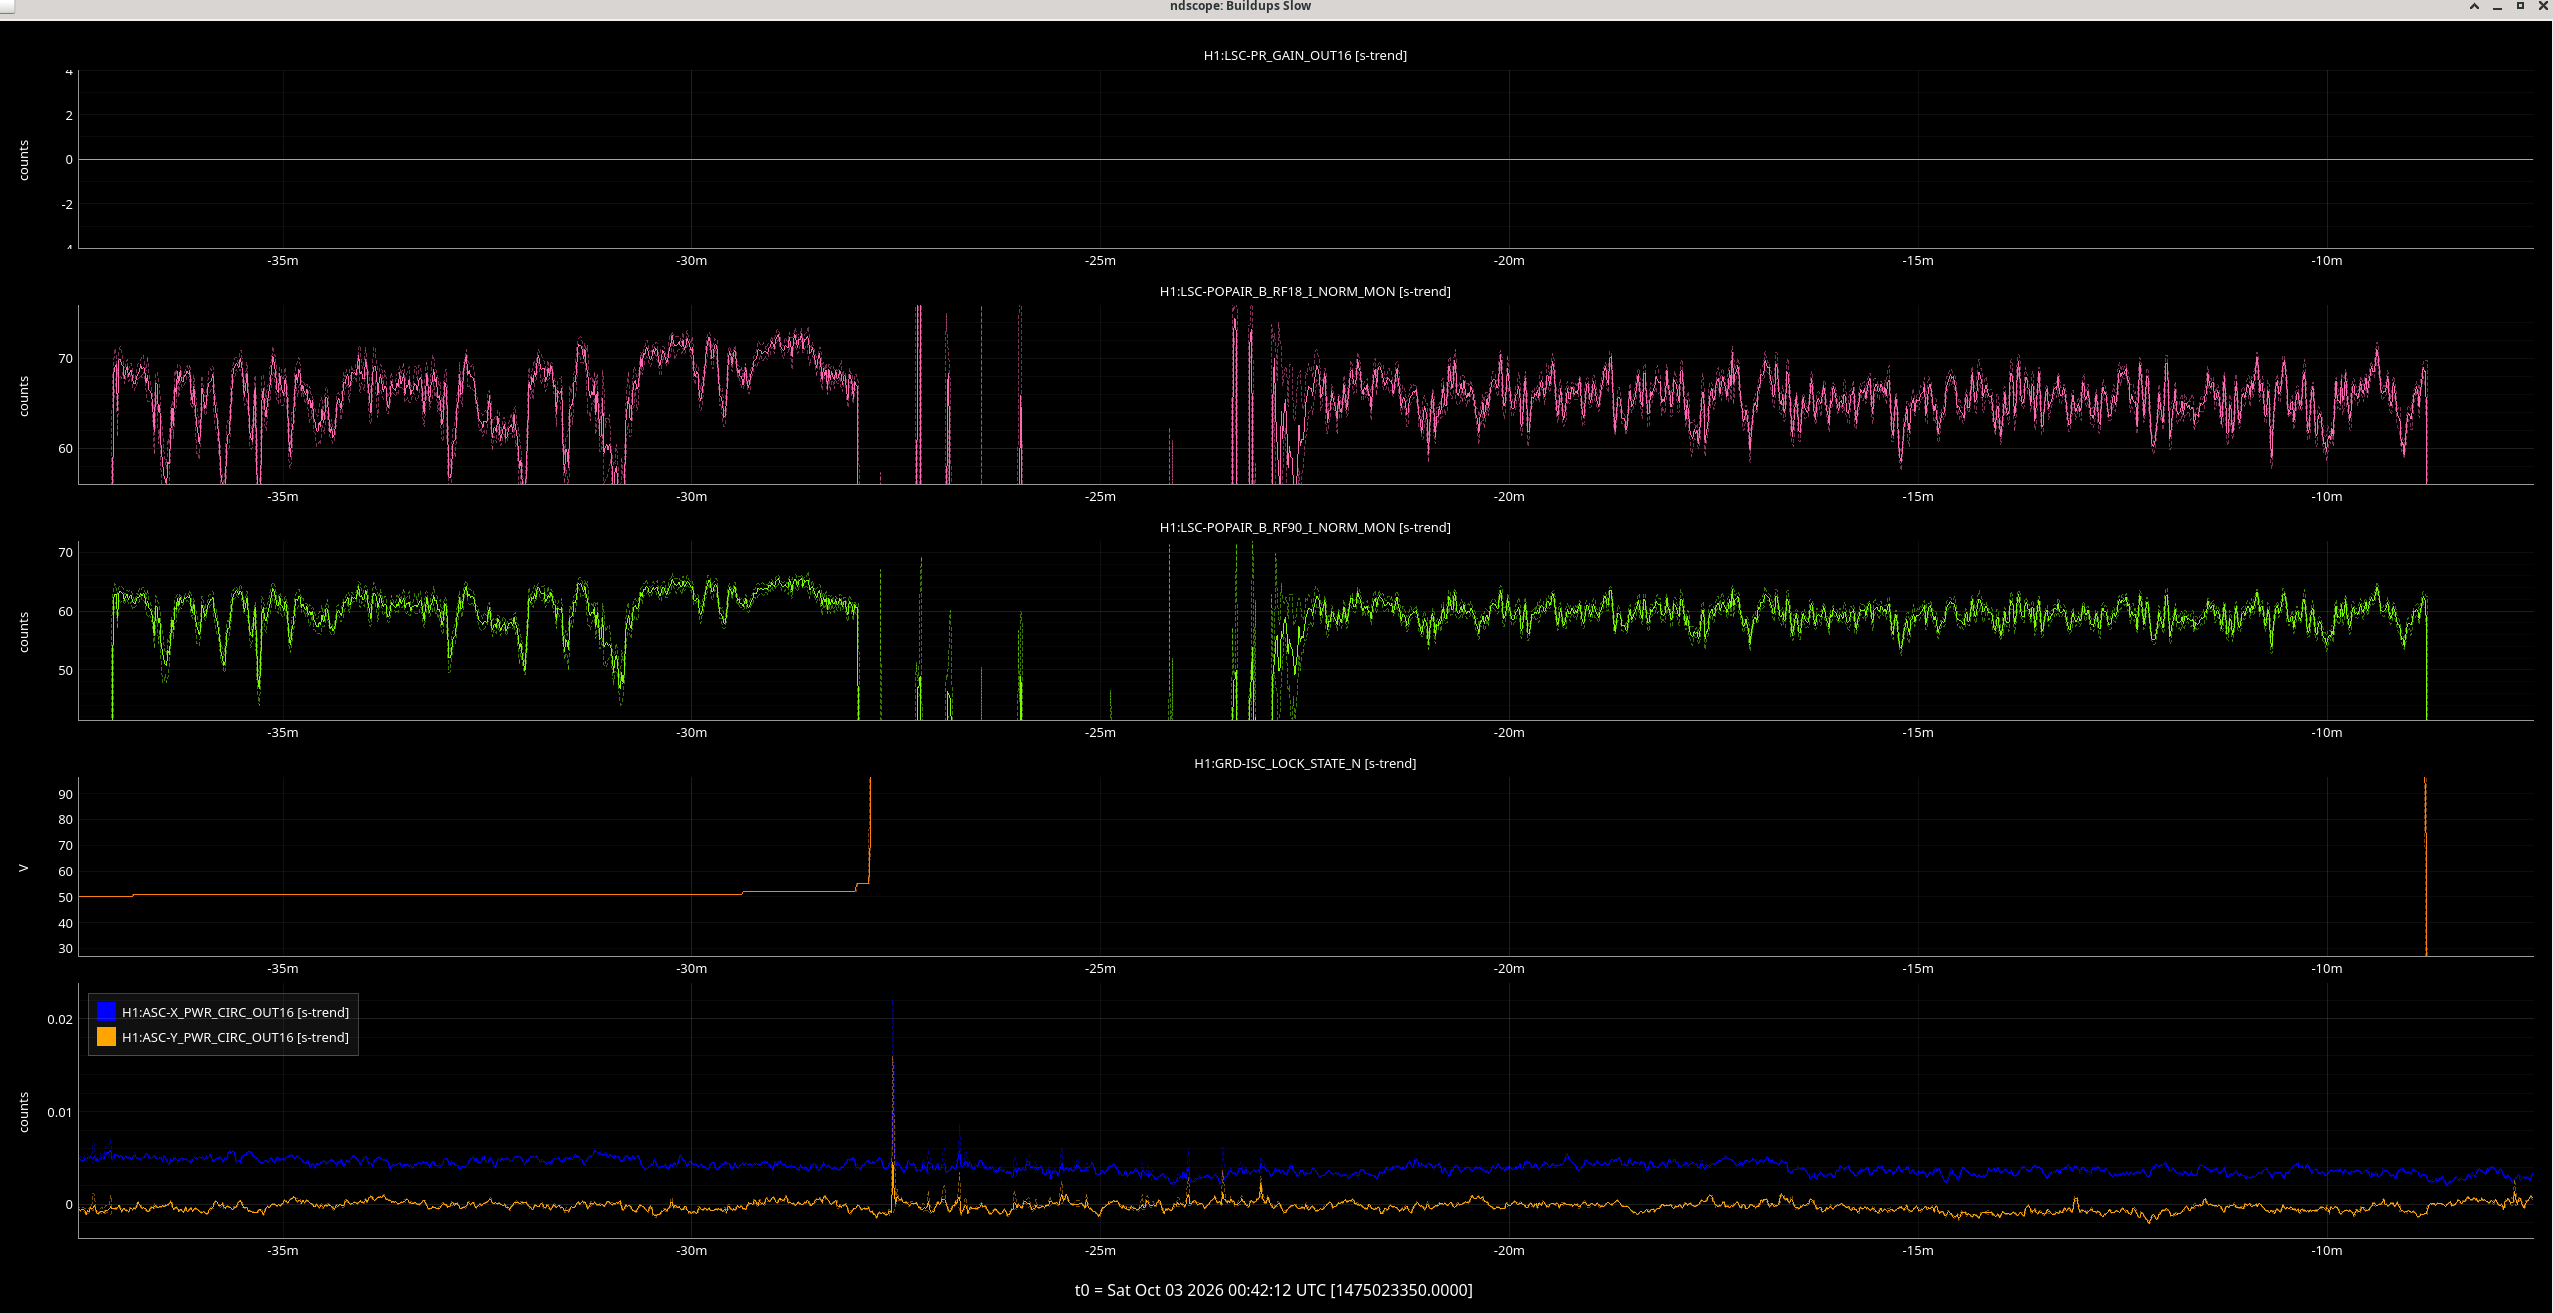
Here are some comparisons of power build ups on POPAIR B:
| time | POPAIR B LF | POPAIR B RF18 I ERR DQ | POPAIR B RF90 DQ | |
| PRMI with arms now |
1474998095 2026/10/02 17:41:17 UTC |
16 | 168 | 148 |
| PRMI without arms now |
1475003027. 2026/09/28 19:30:50 UTC |
4.2 | 38 | 36.6 |
| PRMI with arms O4 |
1432434482 2025/05/28 02:27:44 UTC |
8 | 74 | 60 |
|
PRMI without arms before BBS swap |
1280075940 2020/07/29 16:38:42 UTC | 5 | 64 | 22 |
| DRMI with arms now |
1474992671 2026/10/02 16:10:53 UTC |
11.8 | 210 | 29 (with mode hopping offset) |
| DRMI without arms now |
1474308909 2026/09/24 18:14:51 UTC |
5.3 | 85 | 11 |
| O4 DRMI with arms |
1432440440 2025/05/28 04:07:02 UTC |
7 | 125 | 17 |
| O4 DRMI without arms | 1255278000 2019/10/16 16:19:42 UTC | 5.3 | 46 | 66 |
Tony and Ryan Crouch found time for PRMI + DRMI without the arms from before the BS swap using state counter, they are writting an alog about that.
| now | before BBS | |
| PRMI no arms/ arms (Keita expects 0.46 91738) | 0.26 LF, 0.22 POP18, 0.26 POP90 | 0.6 LF, 0.86 RF18, 0.36 |
We seem to now get more of an increase in build ups that we would expect from locking the arms, and we have more light on the diode than in O4. We do not know if we might have had clipping in this in air path during O4.
Some changes:
If anyone is looking for times that the PRMI is locked and the ALS COMM was Down, then Ryan C. Went ahead and found all those times for ya.
please see the following attached text files.
PRMI35-Locked_NoALS100_preBS.txt is a list of GPS time when H1:GRD-ISC_DRMI_STATE_N= 35 (in a PRMI state) AND H1:GRD-ALS_COMM_STATE_N = 100 (the Down State)
This was created via a tool called statecounter found in /ligo/gitcommon/statecounter.
To run this particular command we used the following:
python3 statecounter.py -chan "H1:GRD-ISC_DRMI_STATE_N H1:GRD-ALS_COMM_STATE_N " -operator "==" -value "35 100" -trend "m-trend" -gpsstart "1198828818" -gpsstop "1459036818" --host h1daqnds0 -port 8088 -output "/ligo/home/anthony.sanchez/Documents/TonysOps/StateCounterResearch/PRMI35-Locked-NoALS100preBS.txt"
I also did the same for a bunch of DRMI states too which are included below.
Thanks for your help dividing and conquering Ryan C!
Thanks for the challenging question Sheila!
The CHETA X arm table telescope was fully aligned as described in gitlab. The performance of the telescope was determined by profiling the beam after L2 and calculating the complex q factor. The profile was measured using the nanoscan beam profiler over a 55cm range between M4 and M5.
This unit was profiled twice the first with a slight angle on L1 to prevent back reflection and then with a reduced angle to determine if this was detrimentally effecting the beam propogation. A non-linear fit was used in both cases to find the q factor which was propogated to the ITM to determine ITM beamsize. Both results show the horizontal axis have a large deviation from the expected q factor and the beamsize at the ITM is reduced by ≈35% and reducing the angle had a minimal effect.
| w0 [um] | z0 [mm] | w @ ITM [mm] | |
| Small angle on L1 | |||
| Horizontal fit | 1486.4±180.5 | -2448.4±269.1 | 36.919 |
| Vertical fit | 916.3±86.3 | -1177.2±143.0 | 57.818 |
| L1 normally incident | |||
| Horizontal fit | 1456.4+/-92.7 | "-2428.4+/-149.4" | 37.659 |
| Vertical fit | 1065.3+/-49.8 | -1384.2+/-79.3 | 50.019 |
Unit 0922 is noticibly non gaussian, screenshot attached, which we believe is consistent with what was observed by thorlabs and is indicated in a paper datasheet shipped to us with the unit. We believe this may be contributing to the deviation from the model.
Ryan Crouch, Corey, Sheila, Keita
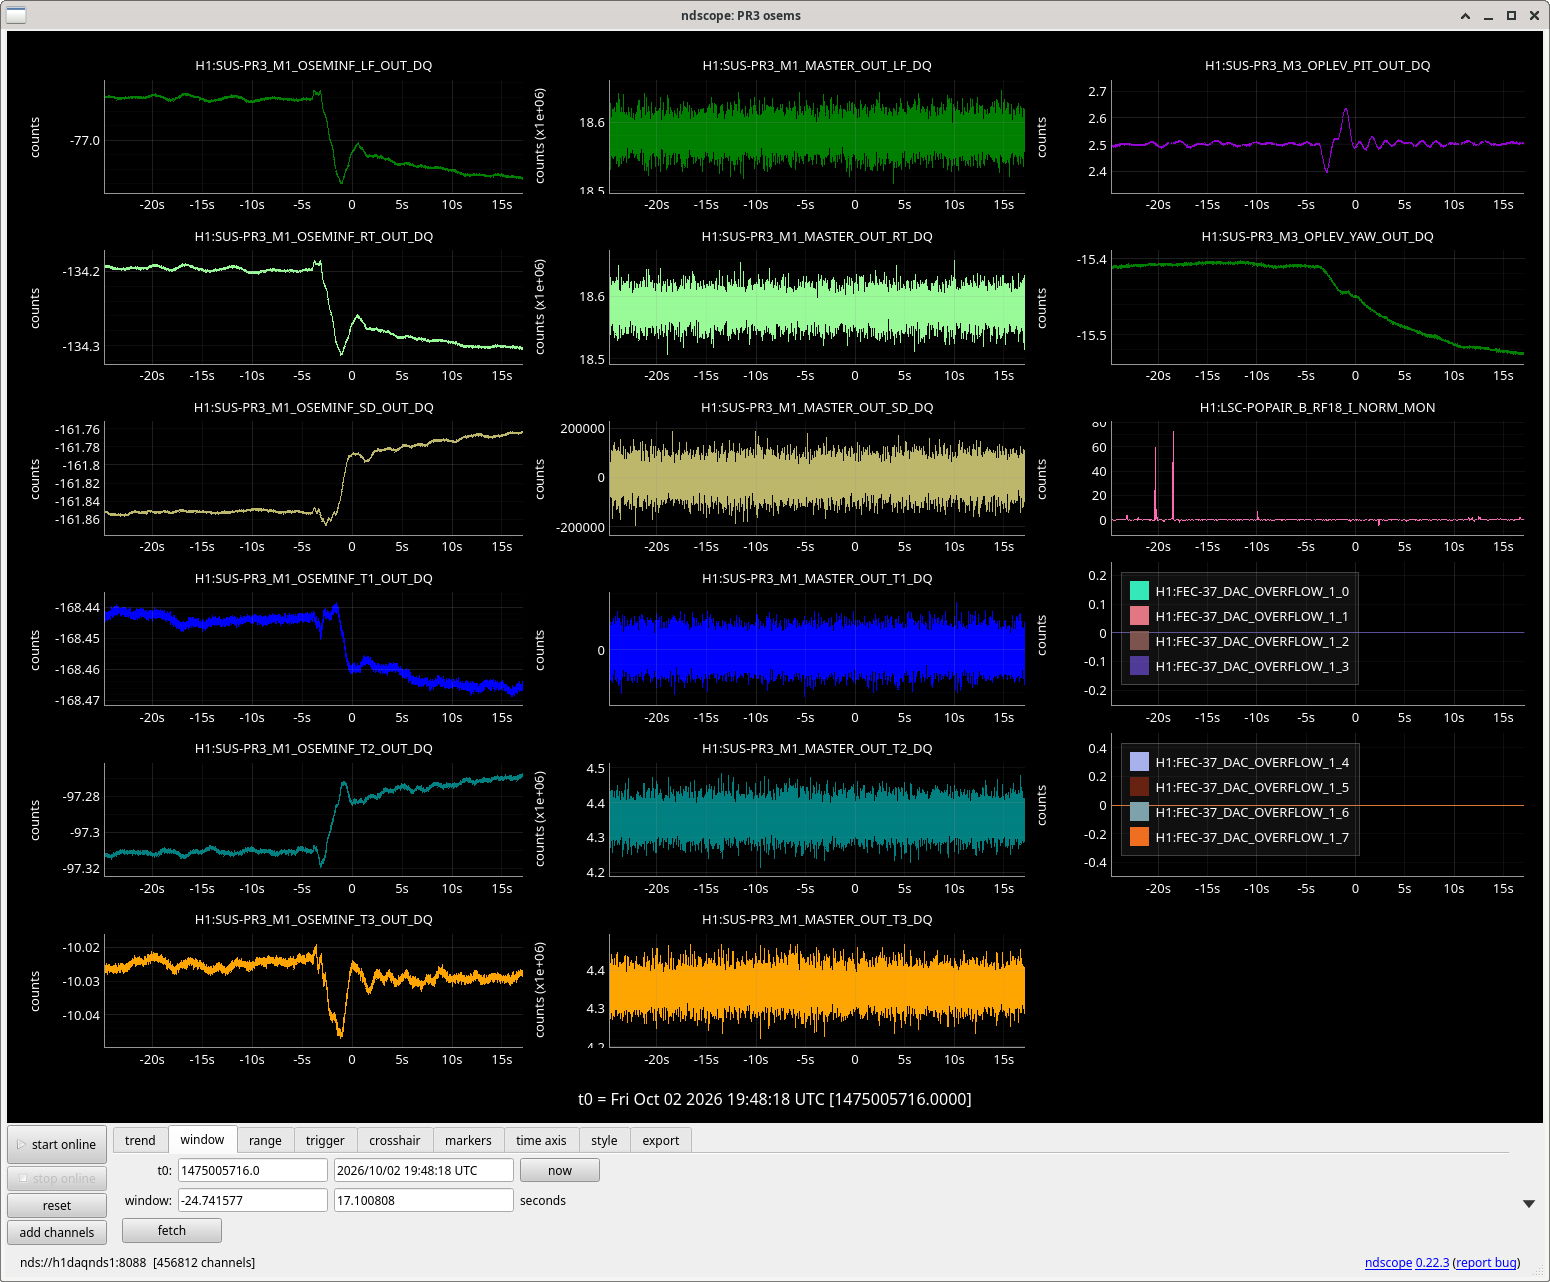
After Corey aliged PRMI, and was waiting for it to lock, we suddenly lost the flashes in PRMI. Ryan Crouch noted that PR3 moved, indeed there is a jump in all 6 top mass osems at the time that we lost the flashes. Perhaps we need to investigate these electronics.
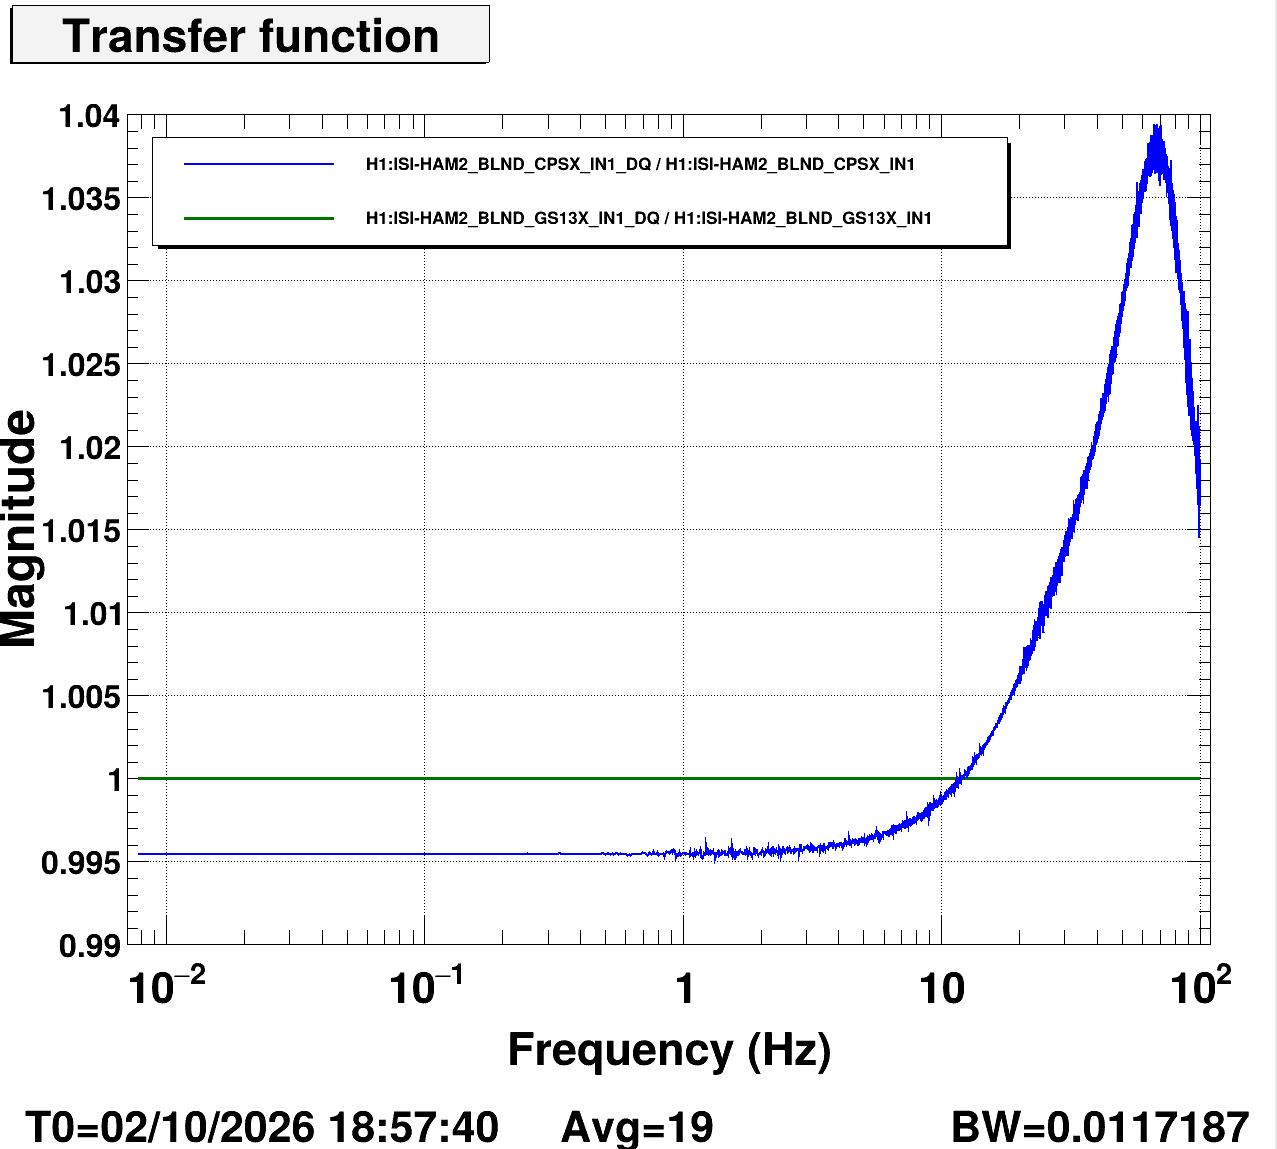
J. Kissel As I'm building up my understanding the ISI system -- in order to eventually understand how to compare it to the SPI signals -- I found one thing I didn't like. When looking at the ISI data offline, we're typically looking at DQ channels -- i.e. those versions of test points that are stored in the frames -- so that we don't have to wait so long to gather data down to 1 [mHz]. Fine. The native rate of the ISI front-end models is 4096 [Hz], so storing every interesting channel at the full data rate would be too much. As such, we down-sample some channels before storage. Fine. Of course, down-sampling requires a digital anti-aliasing filter, often referred to as the "DAQ down-sampling filter." These are defined in T1600059 and the front-end in terms of "factor-of-reduction from native sampling frequency," e.g. if the native rate of the model is 4096 [Hz] and you chose to store the channel at 2048 [Hz], then you apply the "2x" filter. We store the inertial sensors, input to the blends e.g. H1:ISI-HAM2_BLND_GS13X_IN1_DQ at 4096 [Hz] so there's no downsampling filter involved. Long ago, we decided that down-sampling the CPS to 512 [Hz] is good. 4096 / 512 = 8x. But there's something very wrong with the 8x down sampling filter in the ISI system. (a) The DC magnitude of the transfer function between raw and DQ channel is 0.9954; i.e. a 0.5% gain loss. (b) The filter's ripple peaks at ~70 Hz with a magnitude of 1.0386. (c) The phase loss at 10 Hz is -9.1 [deg]. It's difficult to tell from the plots in T1600059 what the magnitude is doing, but I thought that these filters were normalized such that *either* the DC magnitude was 1.0, or the peak of the ripple is 1.0. Neither is true. But, far worse -- the 8x filter phase in the design doc says its only losing -0.5 [deg] of phase at 10 [Hz]. We should fix the issue with the filter, and/or use a higher down-sampling rate. If there's confusing stuff like this happening at such a base level, it makes it that much harder to interpret / compare the already confusing sensor signals.
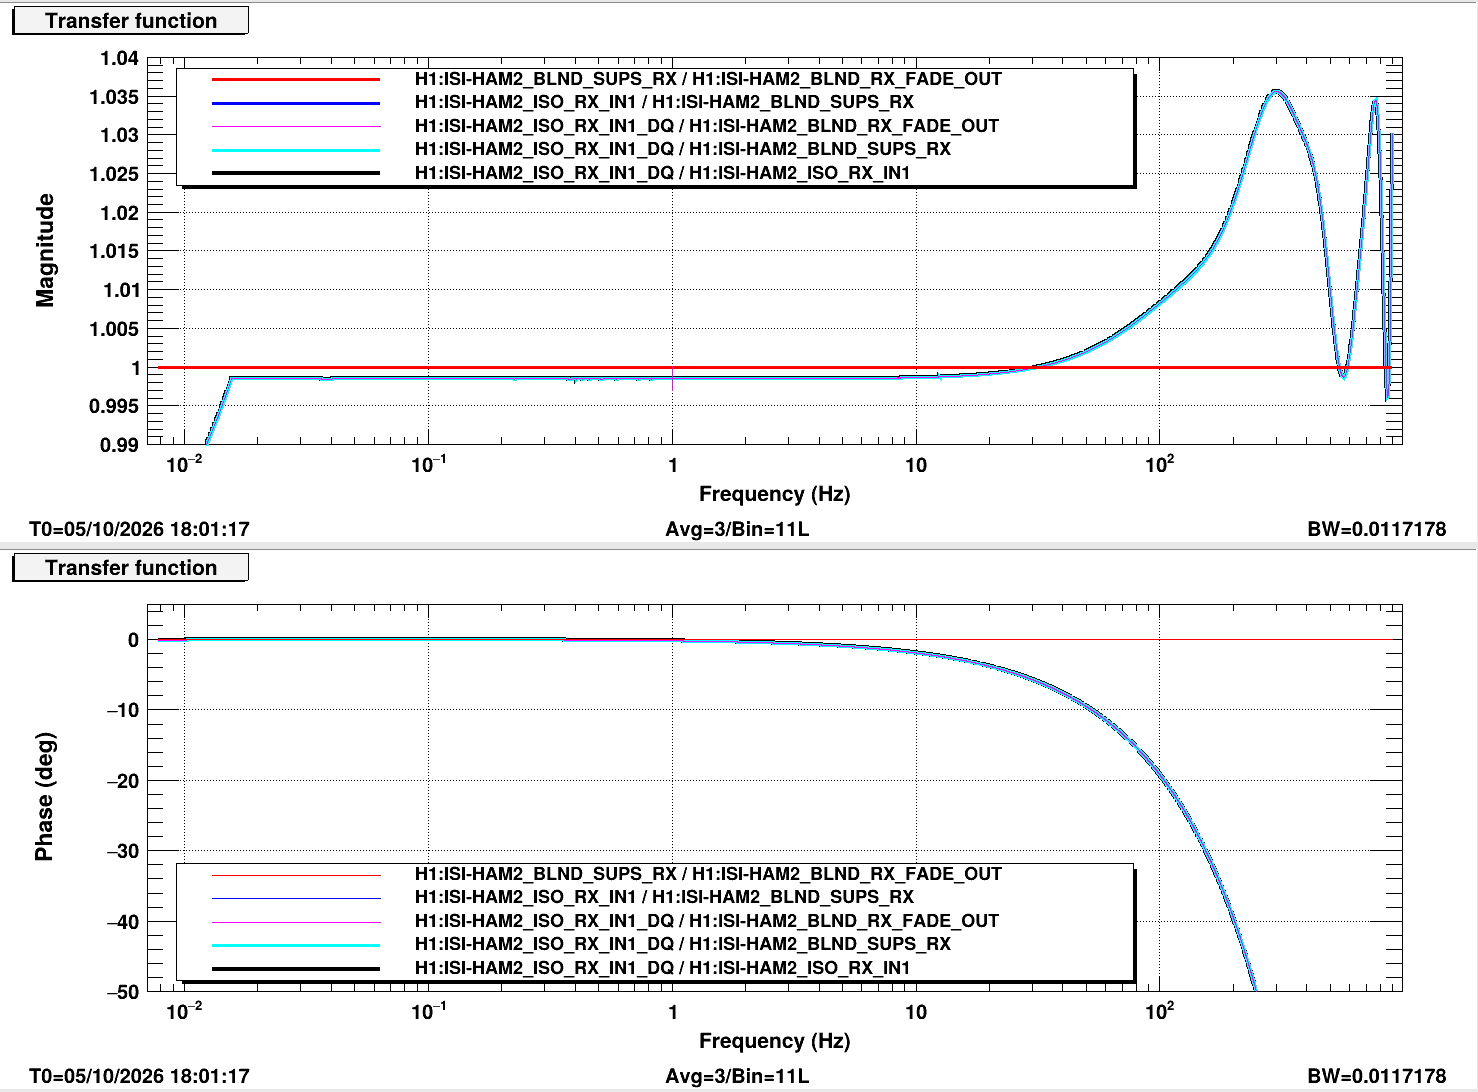
A similar thing is happening with the 4096 [Hz] to 2048 [Hz] down sampling. This should be T1600059's "2x" filter, with a phase loss of (a little) less than 1 [deg] at 1 [kHz]. I attach a measurement of this filter transfer function using otherwise identical channels, H1:ISI-HAM2_BLND_RX_FADE_OUT (4096 [Hz] test point, not stored in the frames) H1:ISI-HAM2_BLND_SUPS_RX (4096 [Hz] test point, not stored in the frames) H1:ISI-HAM2_ISO_RX_IN1 (4096 [Hz] test point as a part of a standard filter module) H1:ISI-HAM2_ISO_RX_IN1_DQ same as all of the above, just stored in the frames at 2048 [Hz]. The same gripes as above with the (supposed) 8x filter: - Non-unity gain at DC, nor unity gain at peak magnitude. I'd take either one (preferring the former), but this is neither. - way too much phase loss -- -1.9 [deg] at 10 Hz, -19 [deg] at 100 [Hz] , etc. This 4096 [Hz] to 2048 [Hz] response most closely matches the 32x DAQ downsampling filter. That would imply the data-storage algorithm is applying the filter as though the native rate of the model is 65536 [Hz] -- the native rate of the IOP model, rather than the native rate of the user model. But that theory is inconsistent with data stored at 512 [Hz], as that would mean it would apply the 65535 [Hz] / 512 [Hz] = 128x filter, which only shows ~ -0.7 [deg] phase loss as opposed to the -9 [deg] shown in the main aLOG. Even the 256x filter only has 1.5 [deg] phase loss at 10 Hz...
Travis, Gerardo, Jordan, Betsy, Tyler, Richard
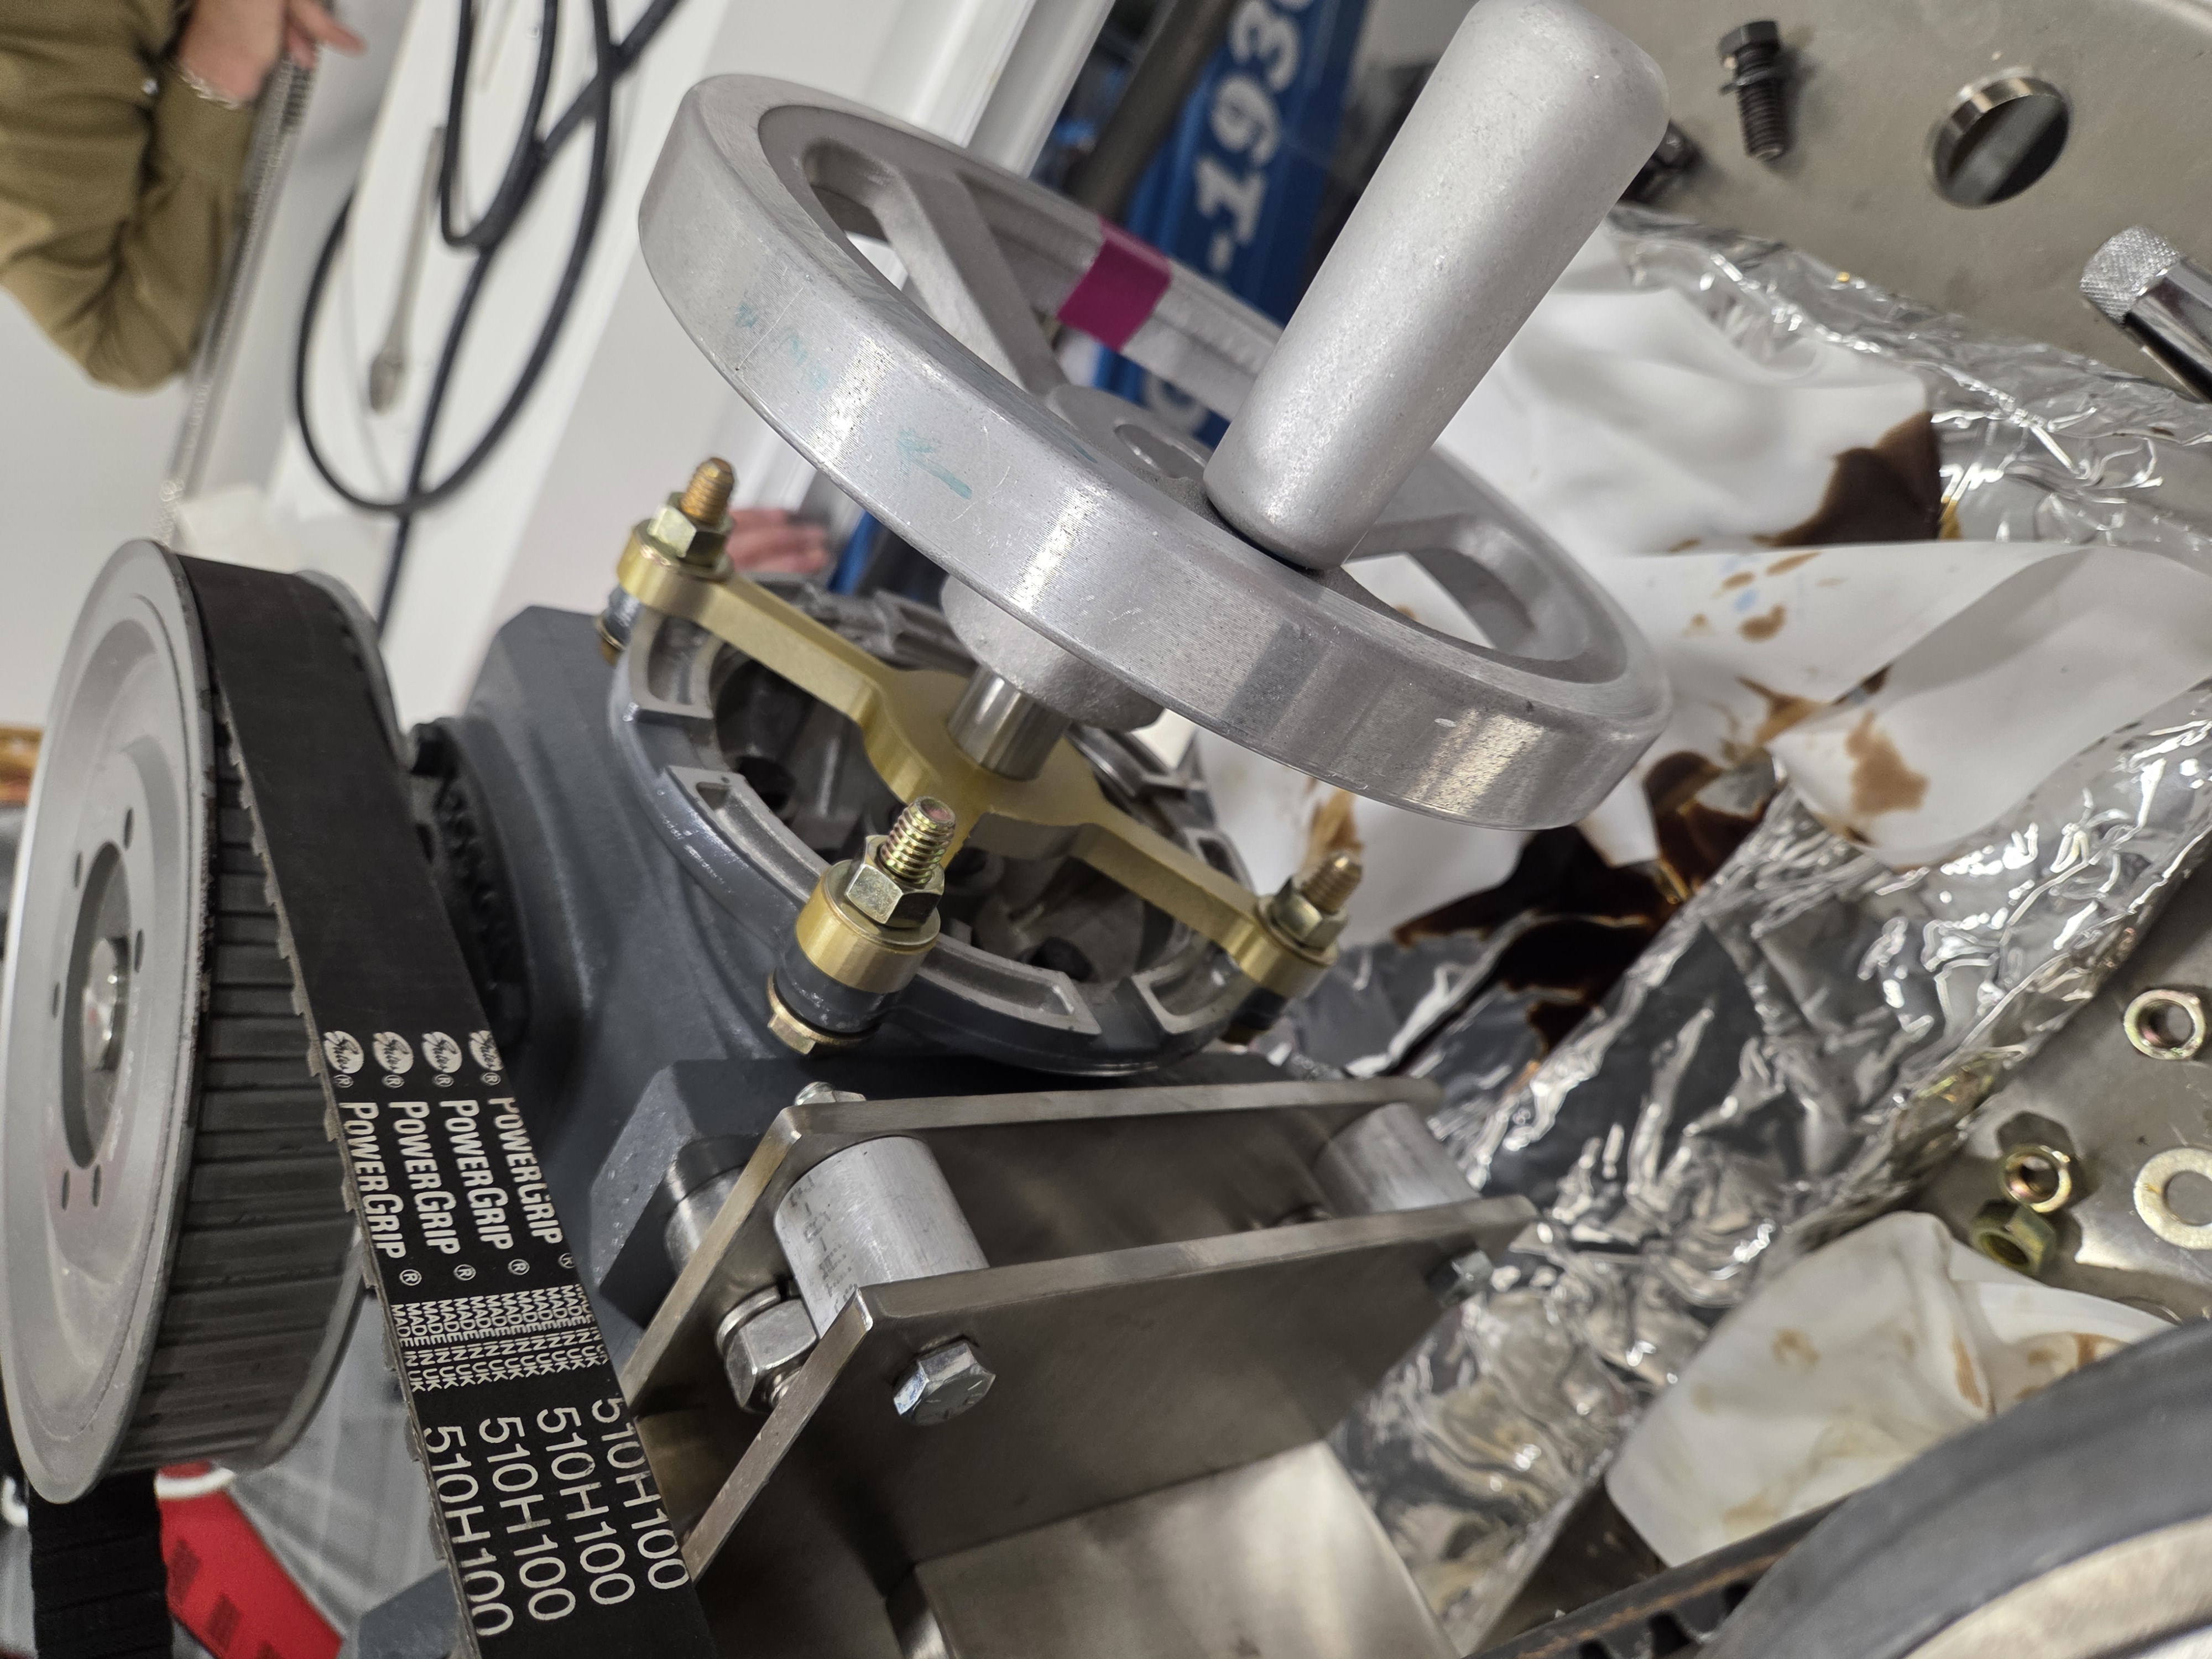
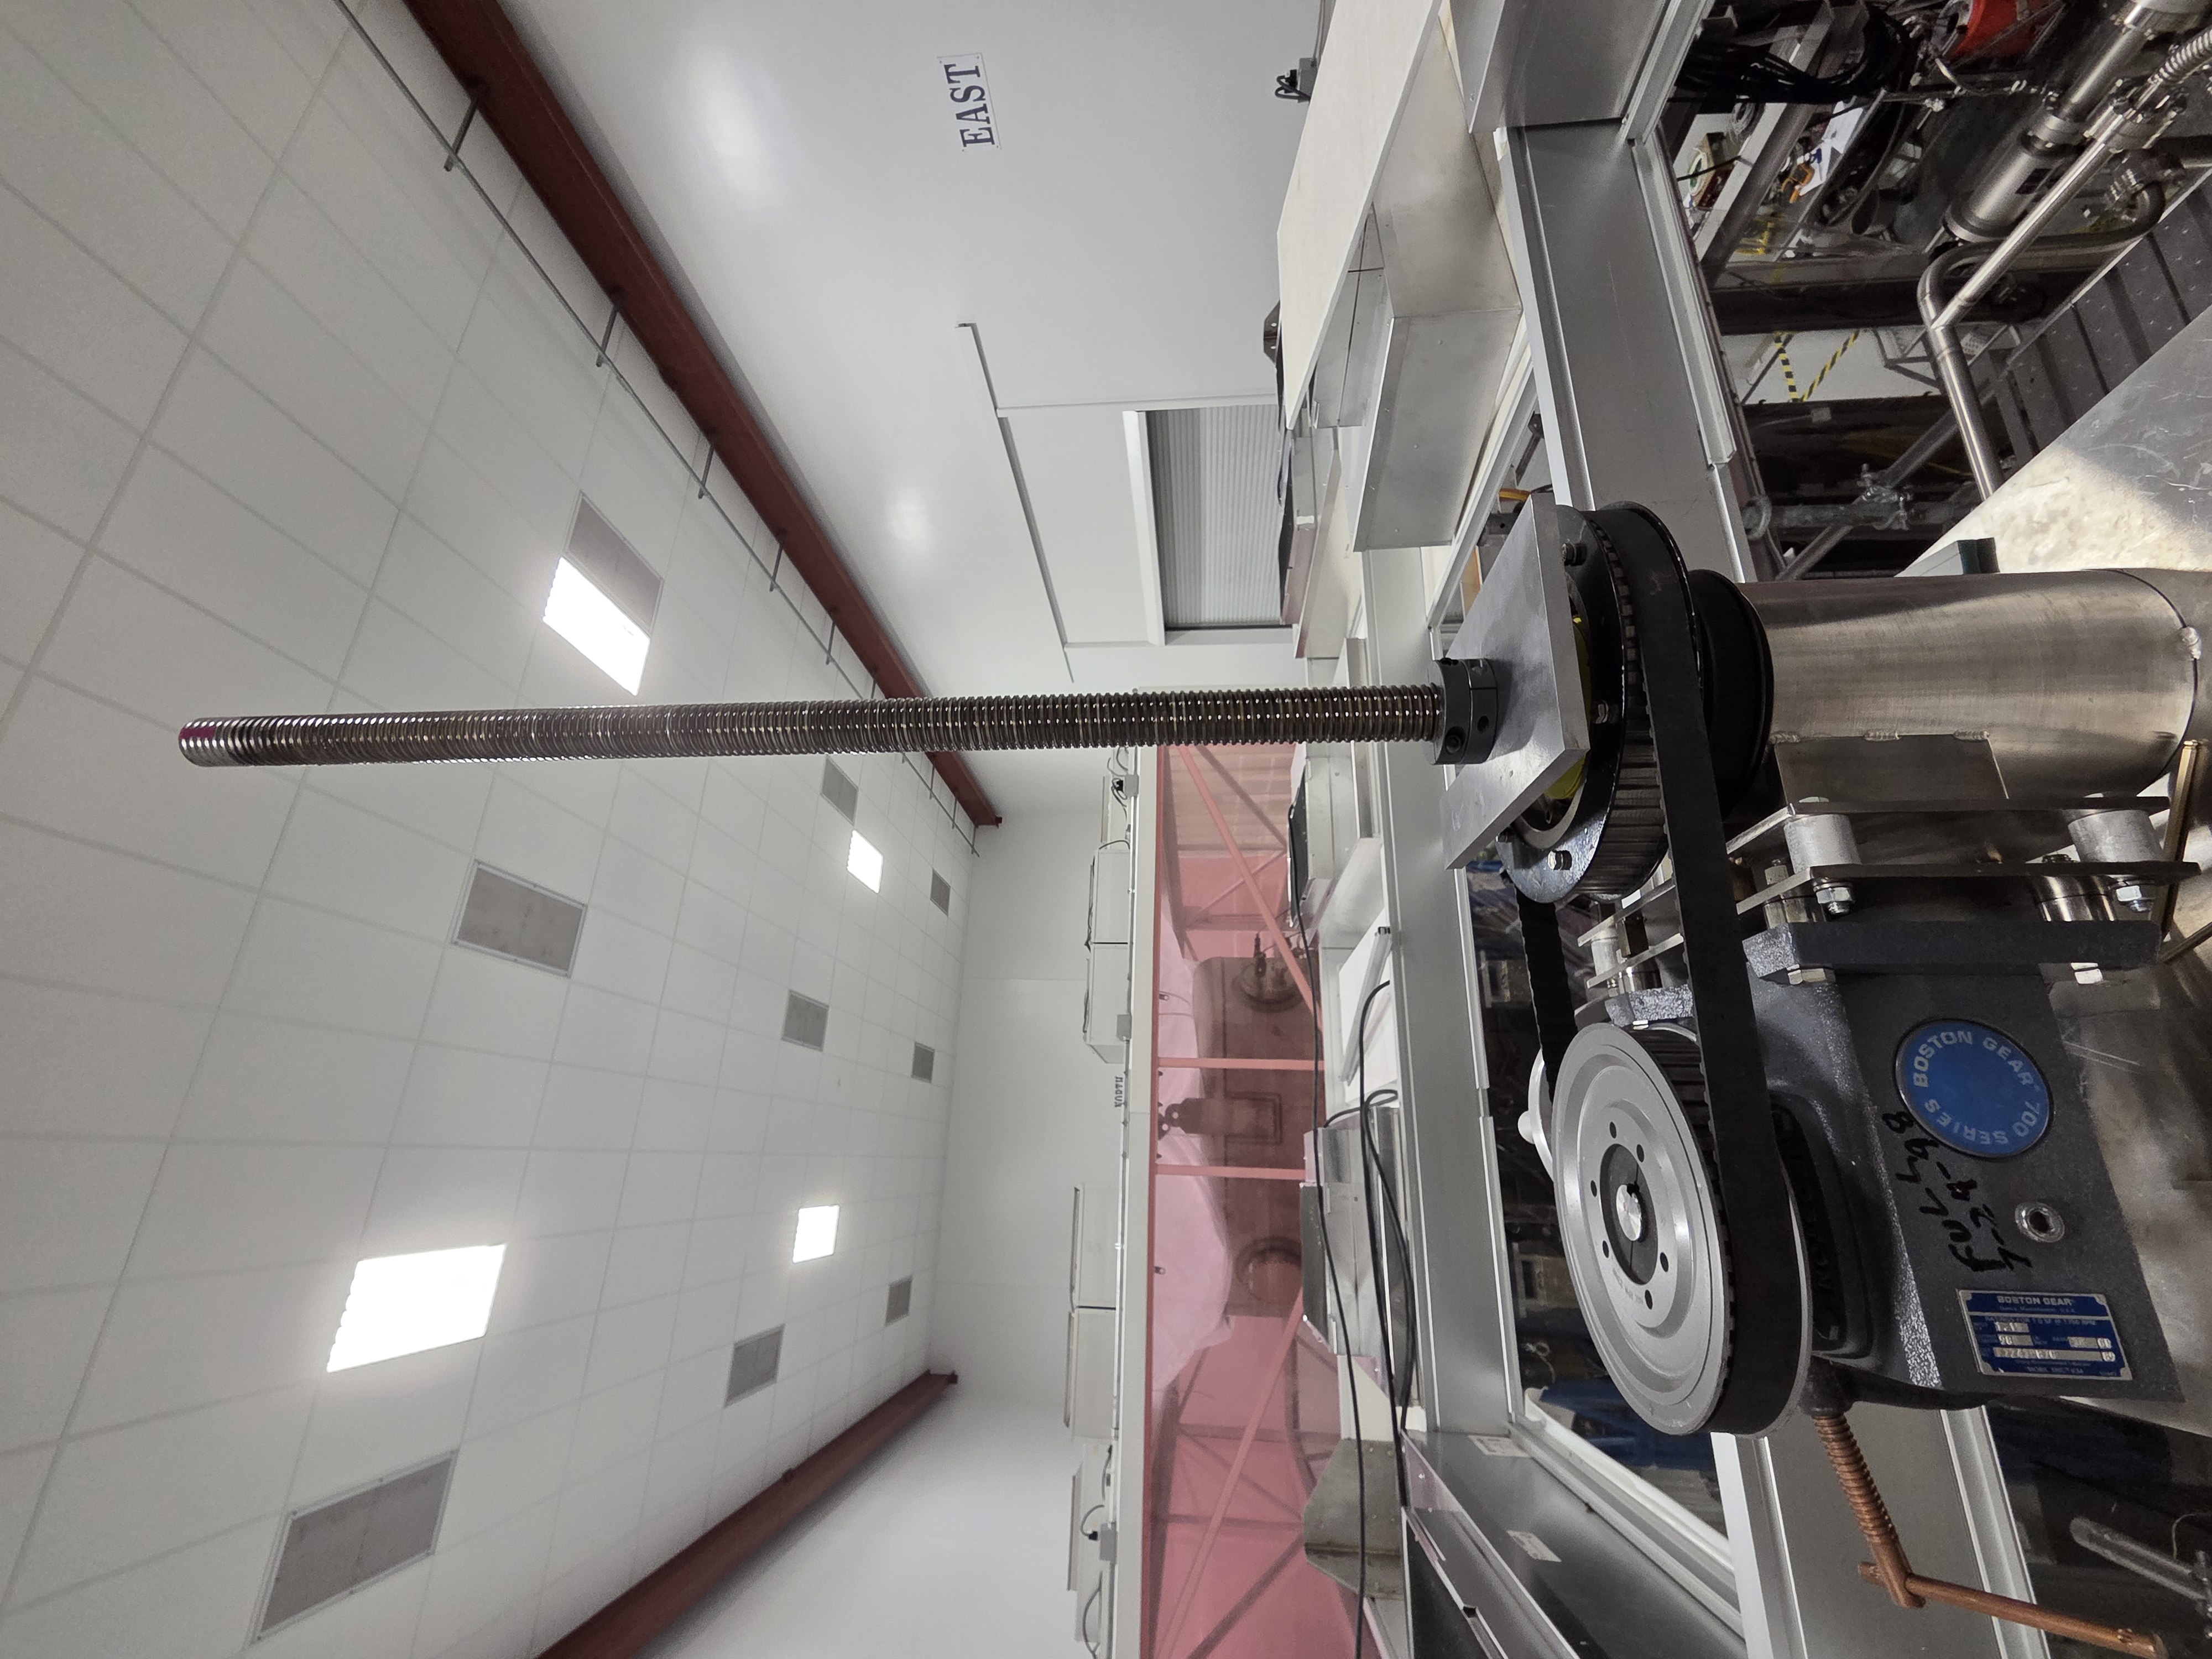
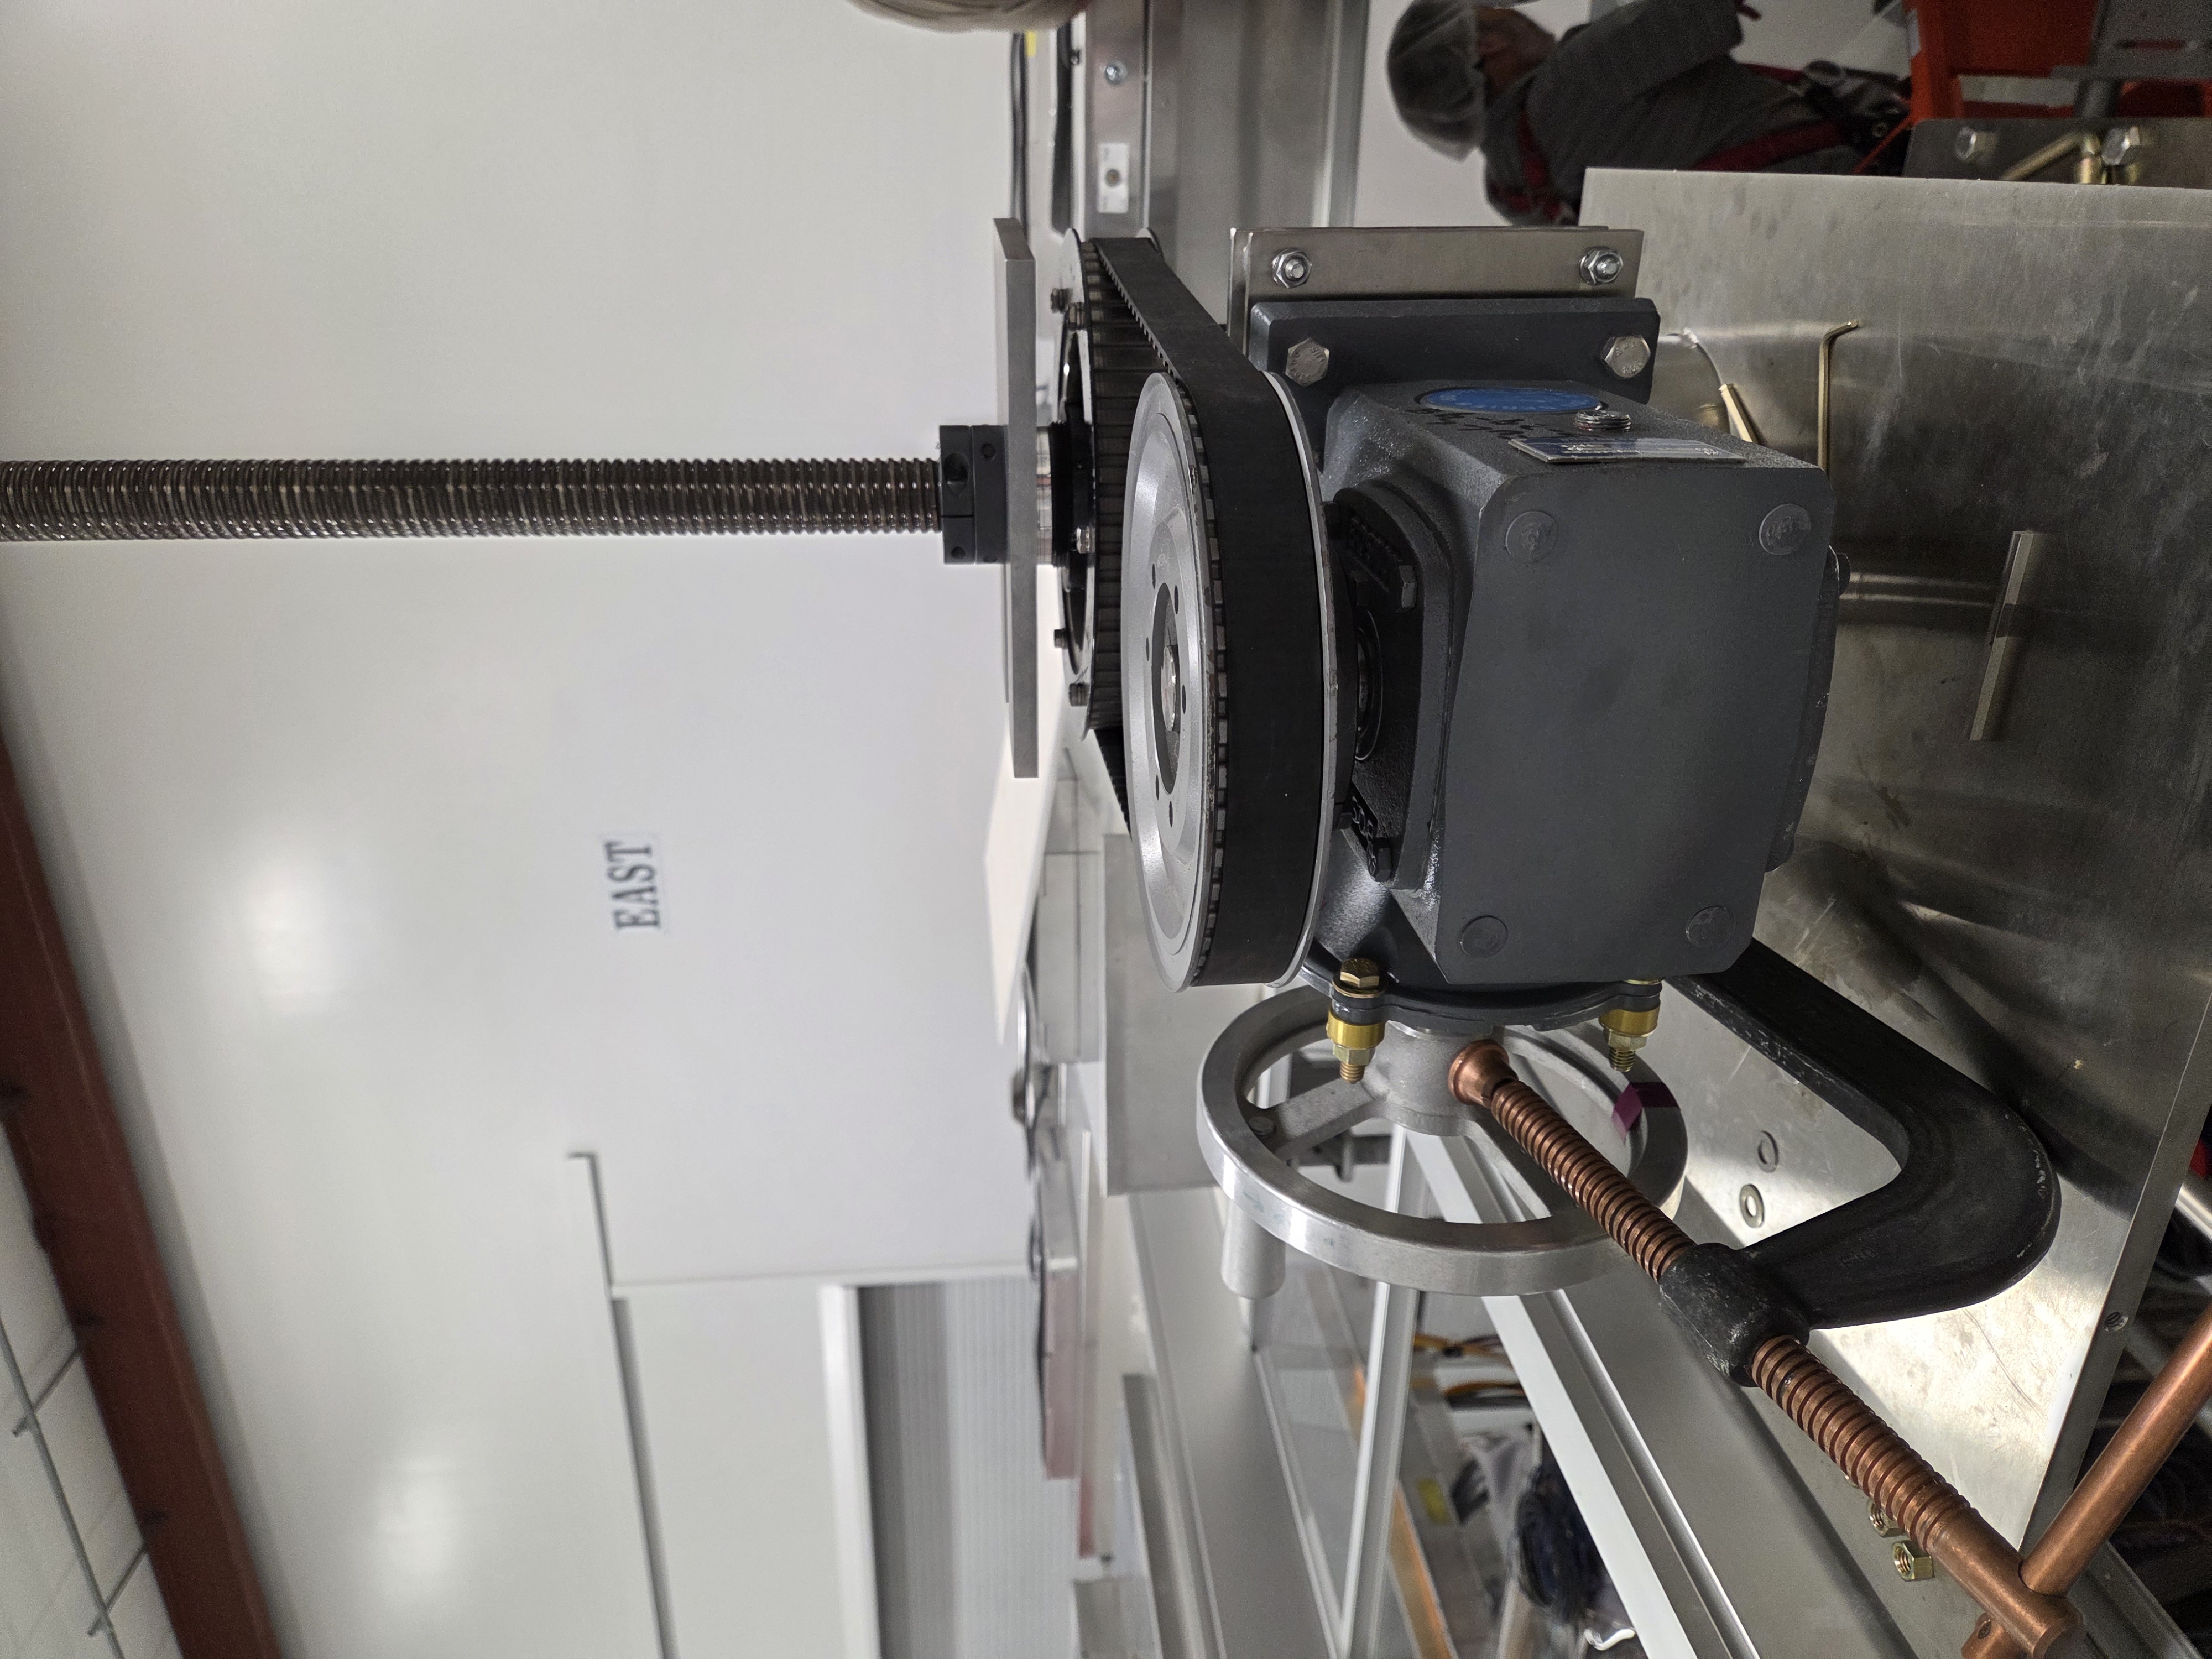
This morning we proceeded with the manual opening of GV20. Tyler had made a nice support for the input shaft on the gearbox to stabilize it while rotating the handwheel. This worked great, no additional oil leaked out of the gearbox after installation.
We had left the valve soft closed overnight, so we started raising the valve at 10:41:59 Pacific by turning the handwheel counter clockwise, stopping every 50 turns to check the ballnut/shaft collar gap. No issues found.
At turn 370, we tested to see if the handwheel would be driven backwards by the weight of the gate. No backwheeling was present, so we continued raising the valve stopping every 50 turns to check ballnut/ball screw height. At turn 620 we decided to increase the interval between stoppages to 100 turns. After turn 1520, the top of the ball screw was about even with the top of the clutch body. At 1920, there was enough exposed ball screw to install the safety plate and the locking collars. Locking collars were torqued to 140 in-lbs.
We then continued raising the valve 300 turns (2") at a time, adjusting the lock collars at each interval, until the medm screen showed green.
Final turn count: 7161
Final ball screw height, +37.75" from top of clutch body (open position/green on medm) Note: Height stamped on side actuator body read 37 7/8" for the open position.
The interlock pin was then set, and lock collars were moved to top of safety plate, and torqued to 140 in-lbs. The handwheel was left installed on the gearbox with a clamp on it to prevent rotation.
Full set of compiled notes/details will be posted to the DCC with noises/turn counts/timestamps/ball screw heights/etc.
Great write-up and nice work, all.
I notice that there are no comments about concerning noises or "clanking"; pending the handwritten "procedure as traveler" with in-process notes, can we confirm that there were no concerning noises during this manual lift?
Key References related to this effort:
- WGV-20 Escalation https://dcc.ligo.org/T2600441
- Opening Procedure https://dcc.ligo.org/E2600314
There were still noises present with the manual opening. I have added a pdf timeline of the opening to the E2600314 DCC page, which outlines the timestamps/number of rotations when noises were heard so it could potentially be matched with PEM data/valve positions.